

A Modeling Method of Large Language Model-based Decision-making Agents for Maritime Search and Rescue
-
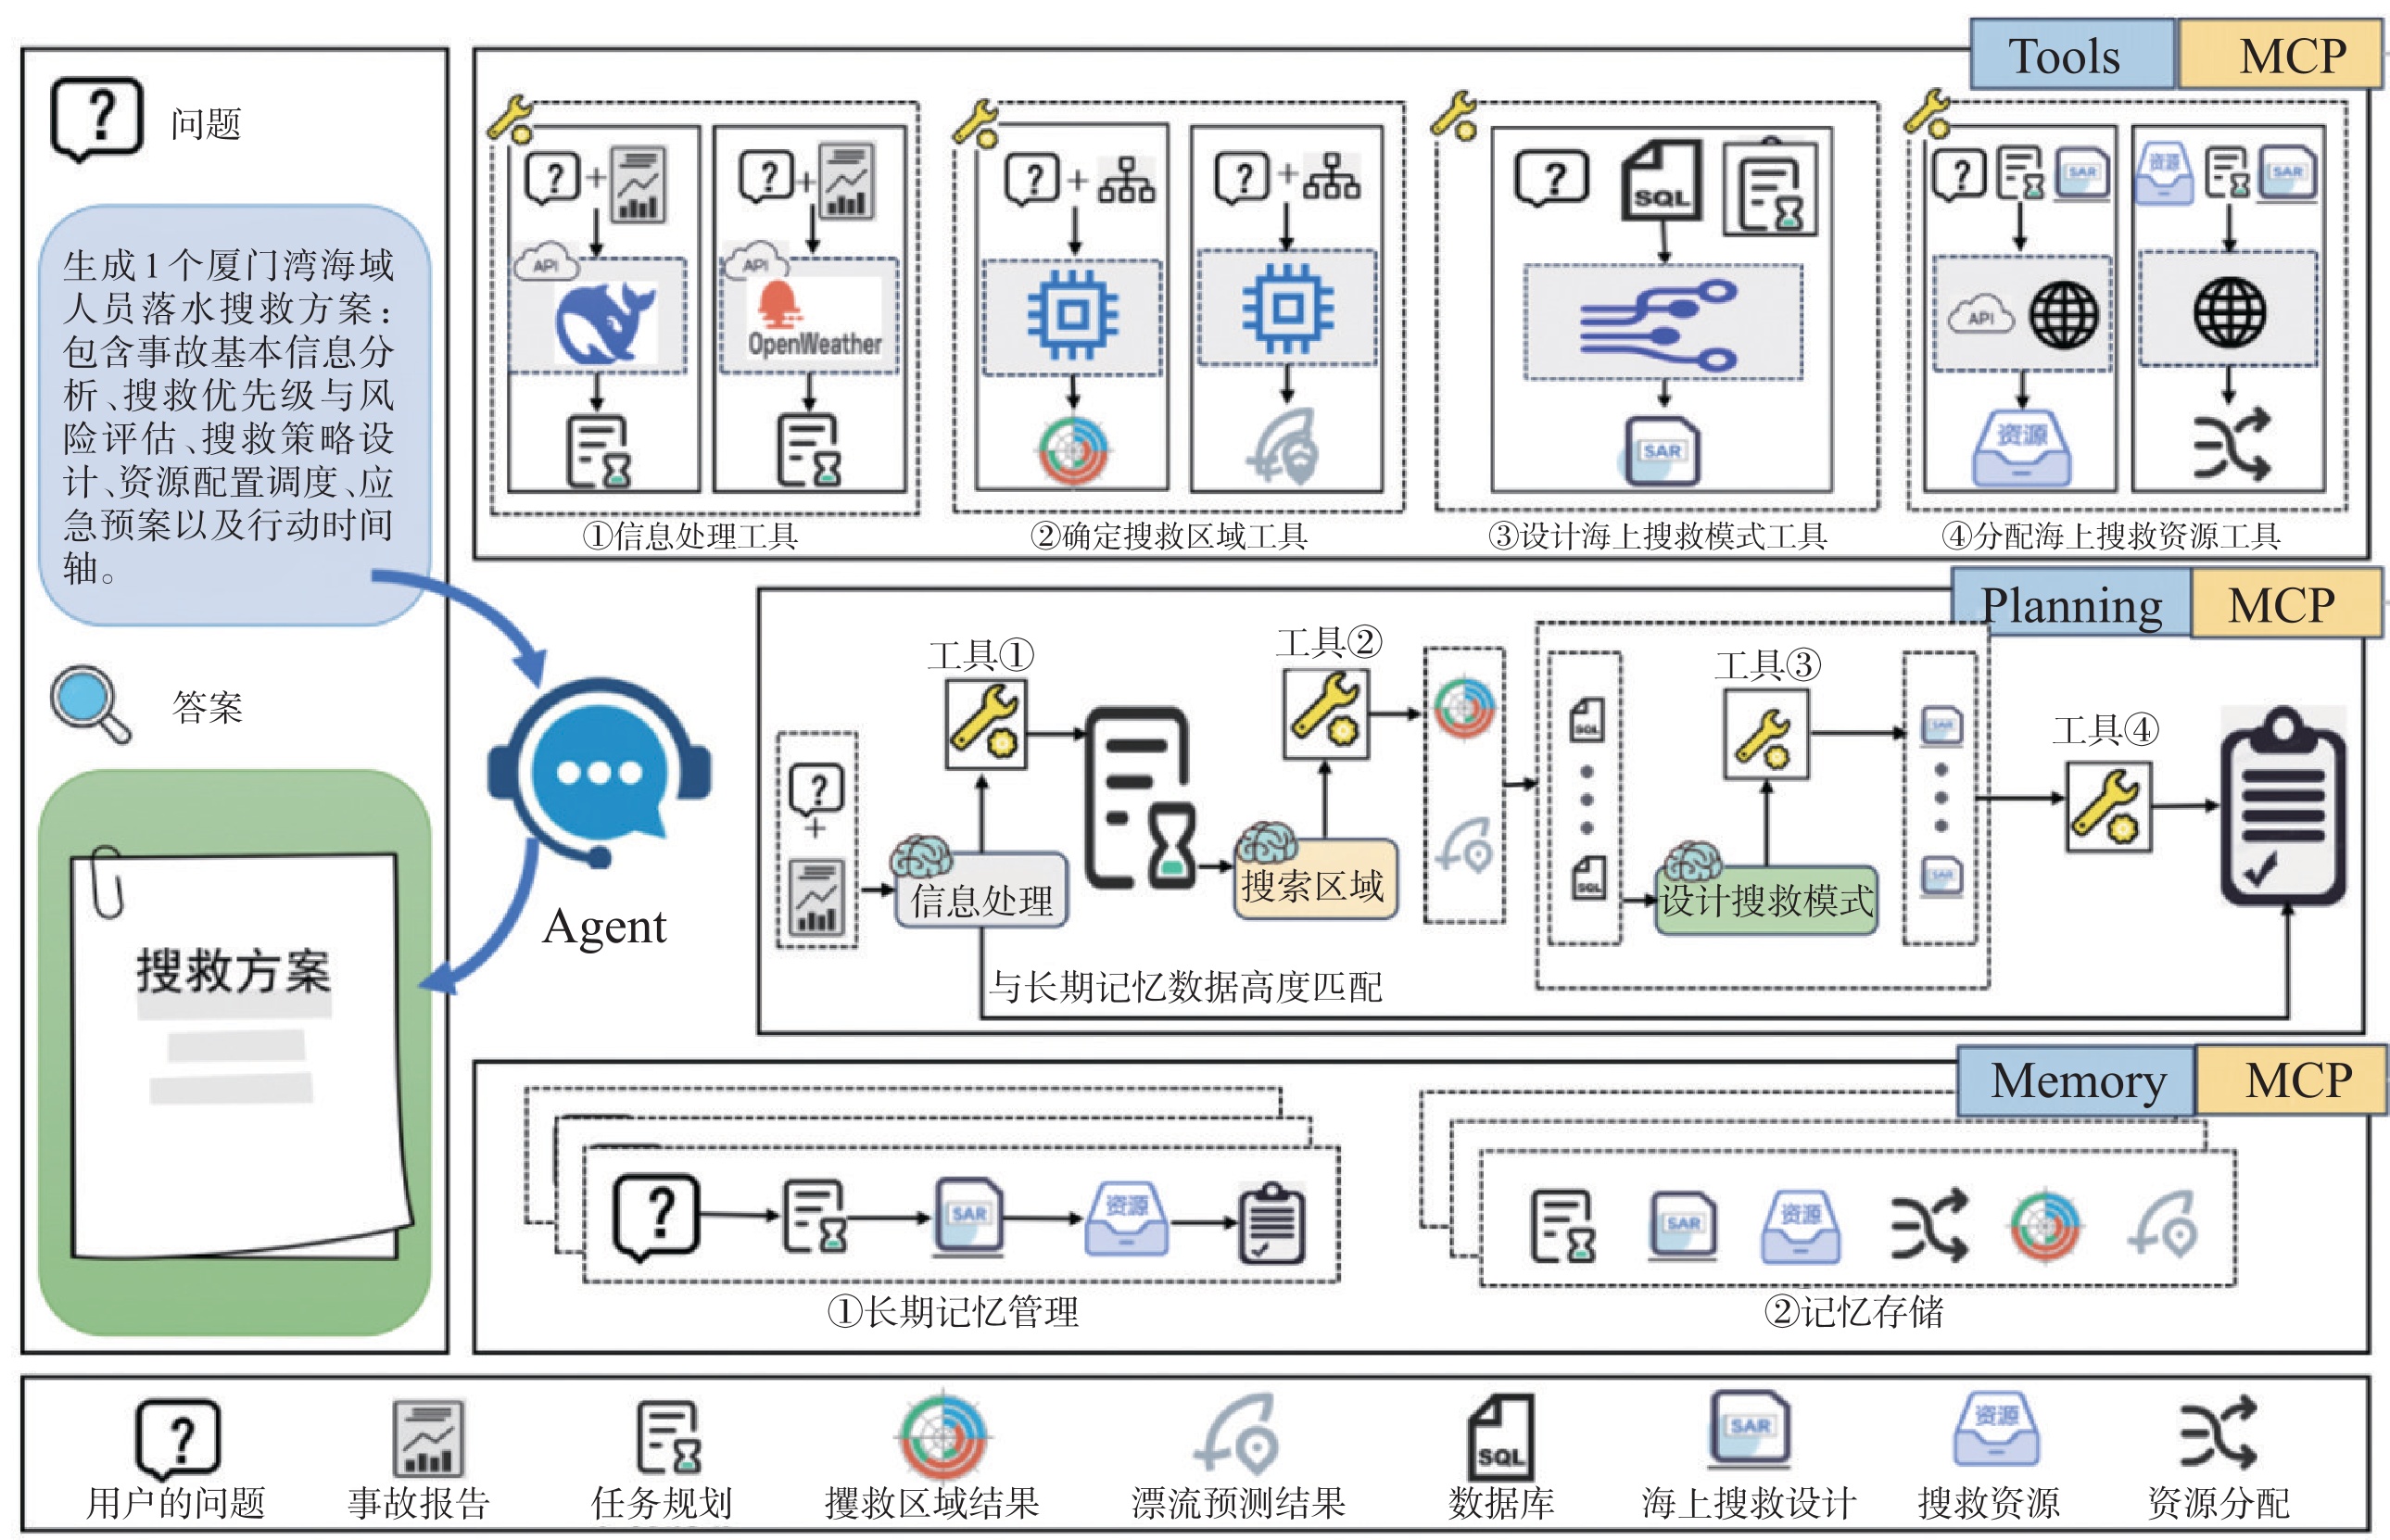
摘要: 当前海上搜救决策面临多源异构信息在语义层面缺乏统一建模方式,难以支撑跨模态信息的联合推理。同时,搜救任务具有多目标约束特性,不同决策目标之间存在显著耦合关系,传统方法往往通过分阶段或经验驱动方式进行处理,缺乏对多目标决策过程的整体推理与动态优化能力。针对上述挑战,本文研究了基于大语言模型(large language model, LLM)为推理核心的海上搜救决策智能体(intelligent search and rescue agent,IS-RescueAgent)建模方法,通过模型上下文协议(model context protocol,MCP)实现跨模态信息的语义级协调,并在统一推理过程中完成多目标决策的闭环推理与优化。新的智能体通过问题识别、信息解析等流程协同机制,实现对求救文本、环境数据和历史记录等跨模态融合处理,并对船只调度、搜索路径和任务优先级等多目标动态优化配置。具体架构层面,新提出的智能体包含信息解析、方案生成与自适应优化3个阶段:①信息处理阶段,基于语义抽取与意图识别机制实现跨模态特征的统一表达;②方案生成阶段,构建融合船舶调度、搜索路径和任务优先级的多目标约束优化框架,实现方案的动态生成与场景自适应;③学习优化阶段,通过任务评估反馈与参数更新形成迭代学习机制。实验结果表明:新智能体在报告相关性(93%)、准确度(92%)和合理性(92.3%)等指标上均优于传统LLM与大语言模型检索增强生成(large language model-retrieval augmented generation,LLM-RAG)方法。此外,本文提出的IS-RescueAgent在多种扰动环境中均表现出良好的适应性与稳定性:在中等风速(≤10 m/s)、资源充足率≥70%、定位误差≤10 m、通信延迟≤200 ms的条件下,误差控制在5%以内,响应效率表现良好。Abstract: Current maritime search and rescue (SAR) decision-making faces challenges in unified semantic modeling for multi-source heterogeneous information. This deficiency hinders joint reasoning across cross-modal data. Meanwhile, SAR missions involve multi-objective constraints with significant coupling between disparate decision goals. Traditional methods often rely on stage-wise or heuristic-driven processing. They lack the capacity for holistic reasoning and dynamic optimization within the multi-objective decision-making process.To address these challenges, this paper investigates a modeling methodology for the intelligent search and rescue agent (IS-RescueAgent), This agent utilizes a large language model (LLM) as the core reasoning engine. By implementing the model context protocol (MCP), the framework achieves semantic-level coordination of cross-modal information. It executes closed-loop reasoning and multi-objective optimization within a unified process. Through collaborative mechanisms like problem identification and information parsing, the agent achieves fusion of cross-modal data.This includes distress messages, environmental data, and historical records.It also enables dynamic optimization for vessel scheduling, search paths, and task priorities.Architecturally, the proposed agent comprises three stages: First, the information processing stage achieves unified representation of cross-modal features through semantic extraction and intent recognition.Second, The strategy generation stage constructs a multi-objective optimization framework for scenario-adaptive plan generation. Finally, the learning stage establishes an iterative mechanism through performance feedback and parameter updates.Experimental results show that IS-RescueAgent achieves a relevance of 93%, an accuracy of 92%, and a rationality of 92.3%. These metrics outperform traditional LLM and Retrieval-Augmented Generation (RAG) approaches. Furthermore, the system demonstrates strong stability under environmental disturbances. Under conditions of wind speeds below 10 m/s and resource availability above 70%, error rates remain within 5%. The system also maintains high response efficiency with positioning errors under 10 m and communication delays below 200 ms.
-
Key words:
- search and rescue (SAR) /
- large language model (LLM) /
- agent /
- auxiliary decision-making
-

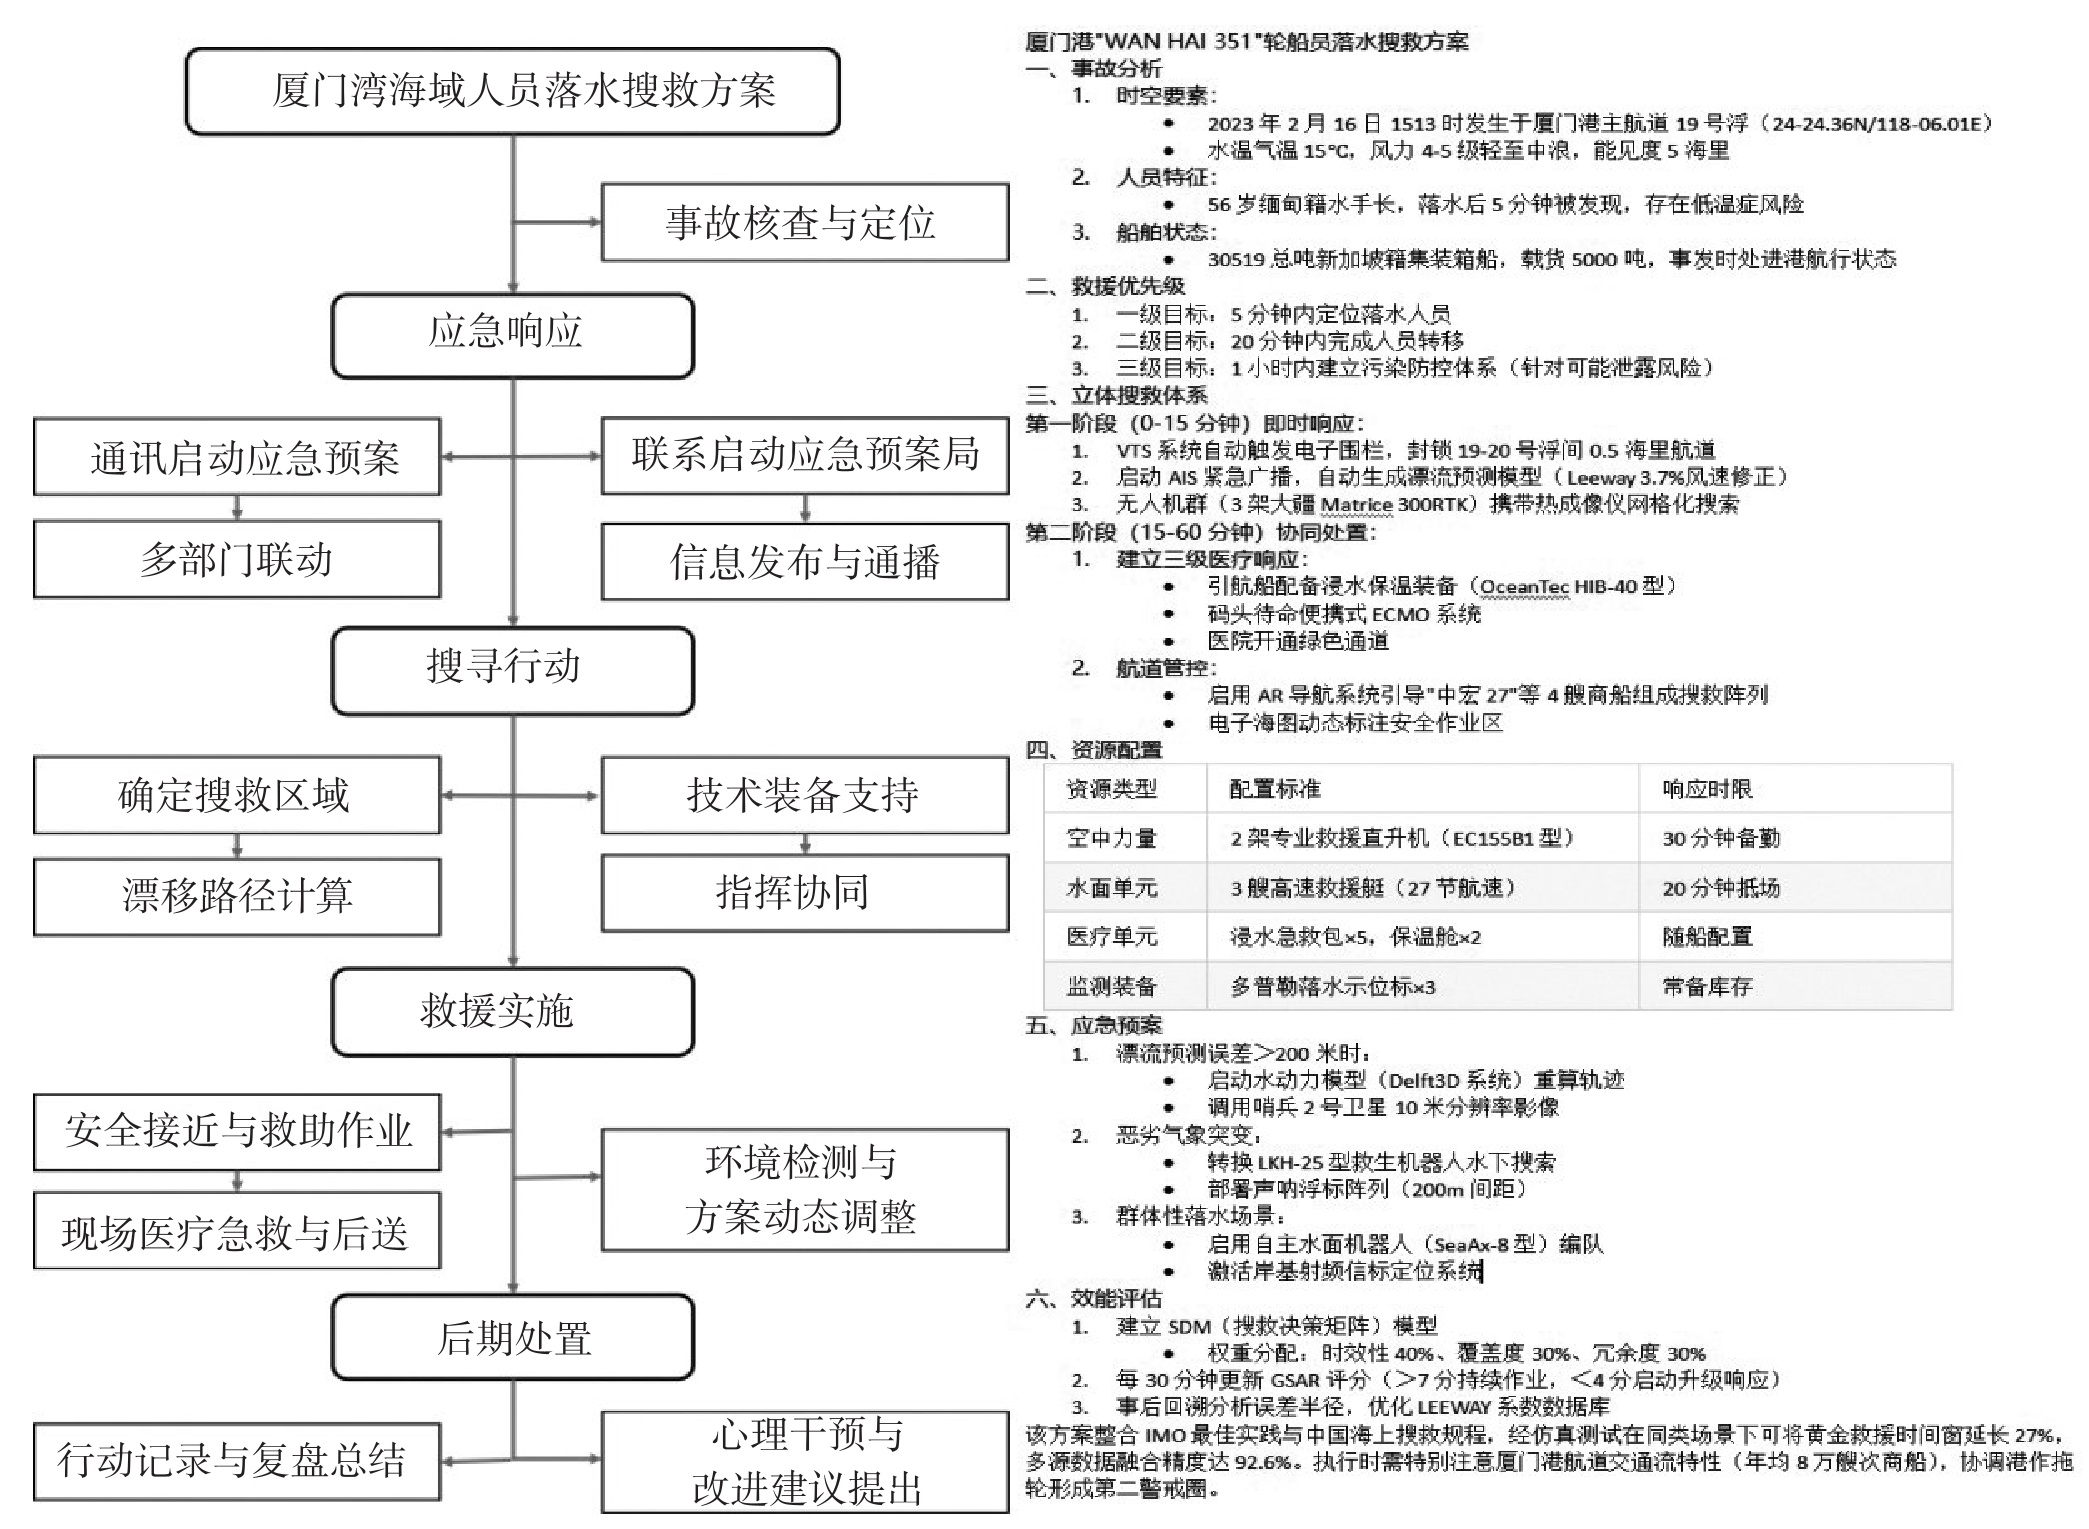
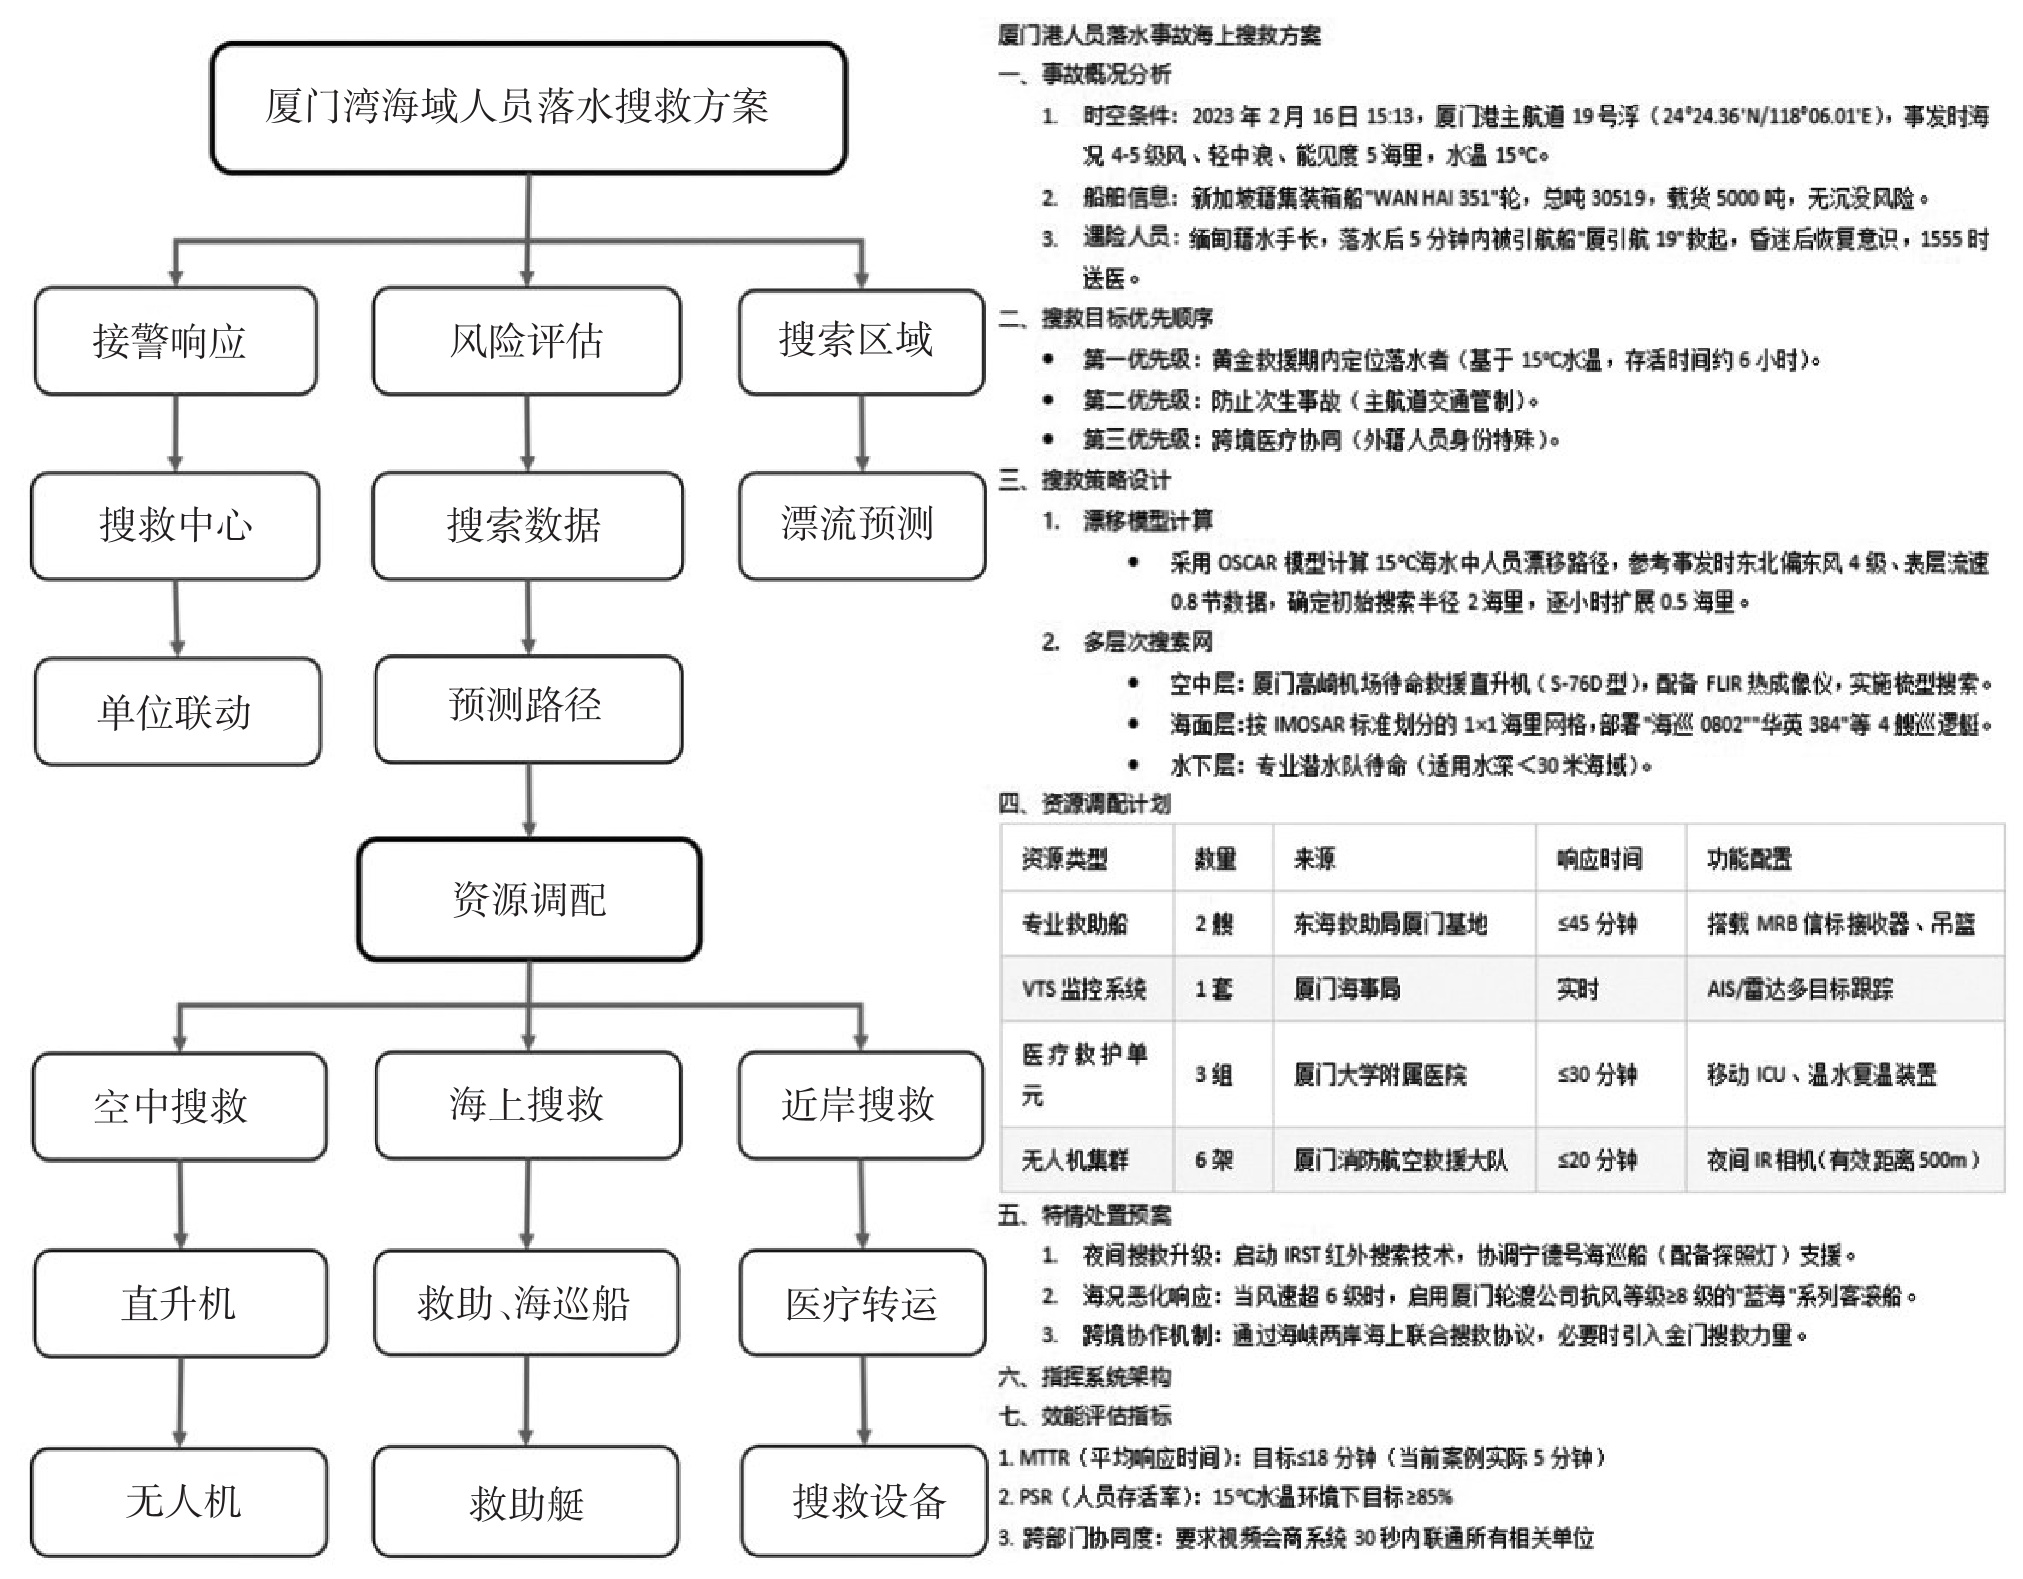
图 5 LLM的思考过程与生成的搜救方案
Figure 5. The thought process and output rescue plan produced of LLMs

图 6 LLM-RAG的思考过程与生成的搜救方案
Figure 6. The Thought process and output rescue plan produced by the RAG-enhanced LLM

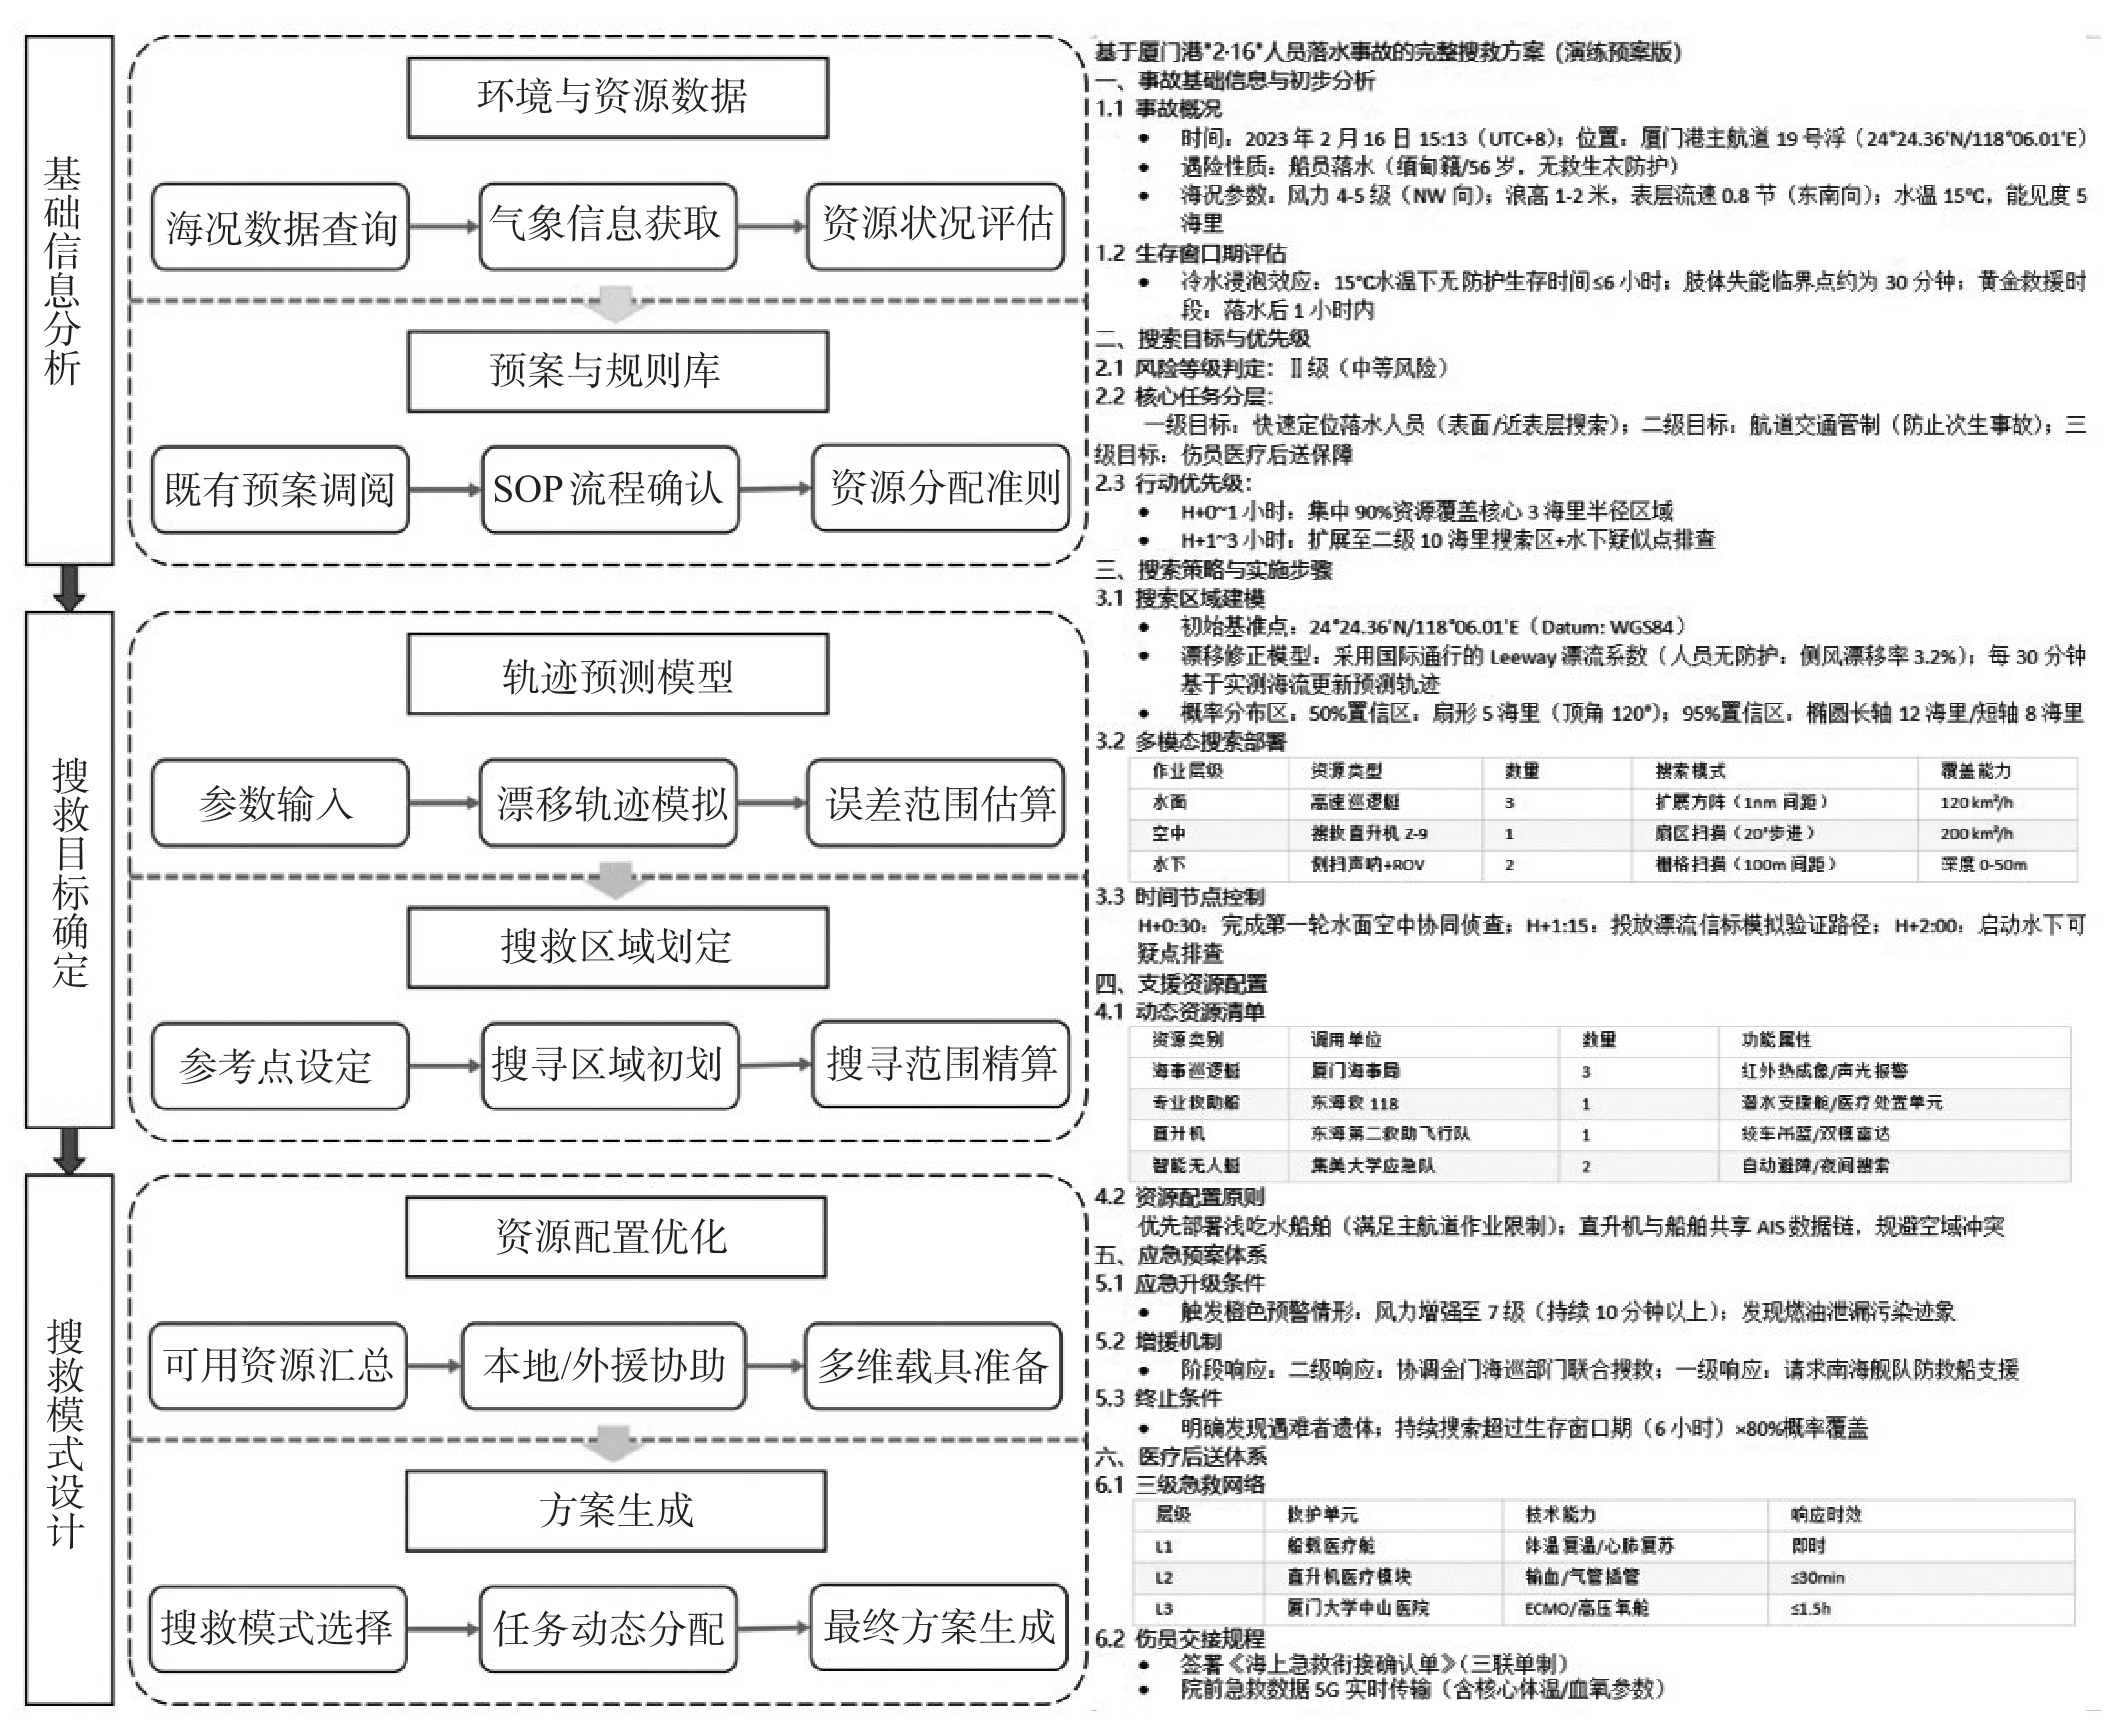
图 7 IS-RescueAgent的思考过程与生成的搜救方案
Figure 7. The thought process and output rescue plan produced by the IS-RescueAgent

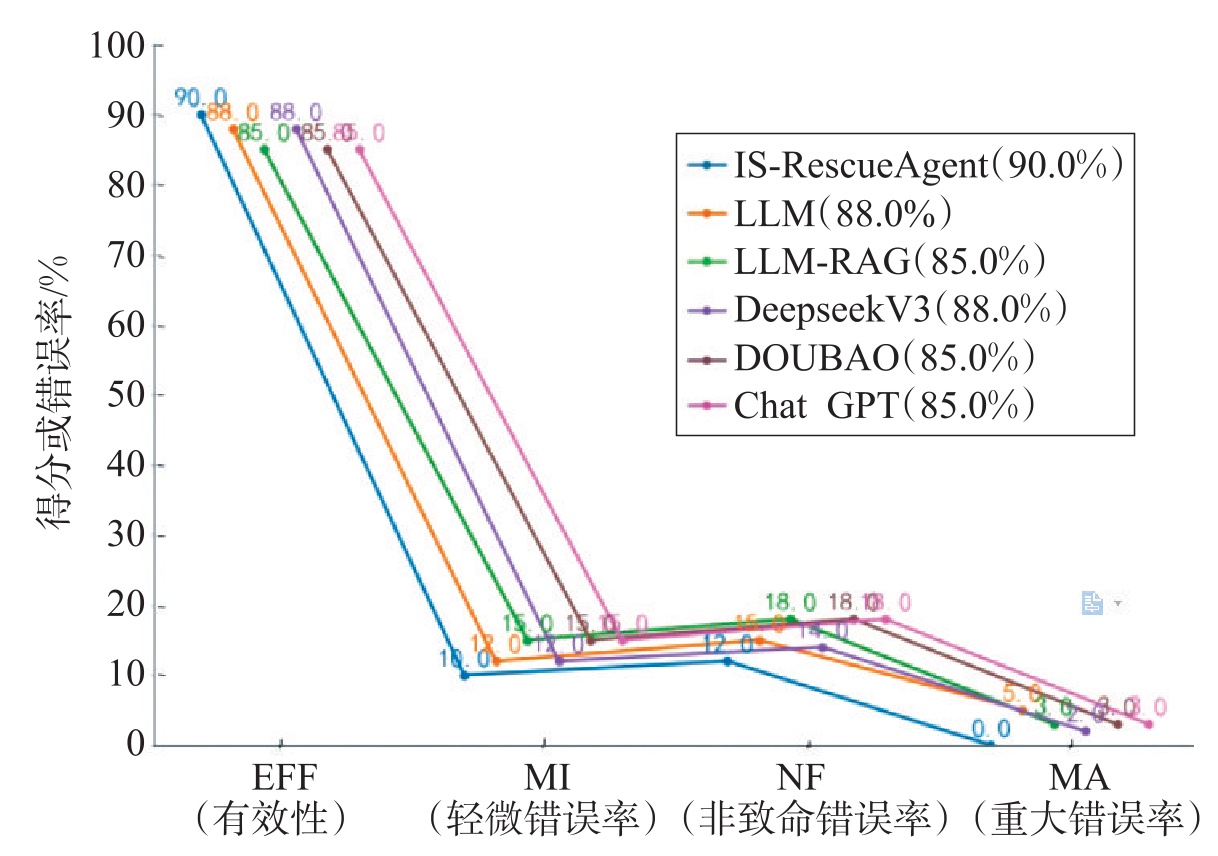
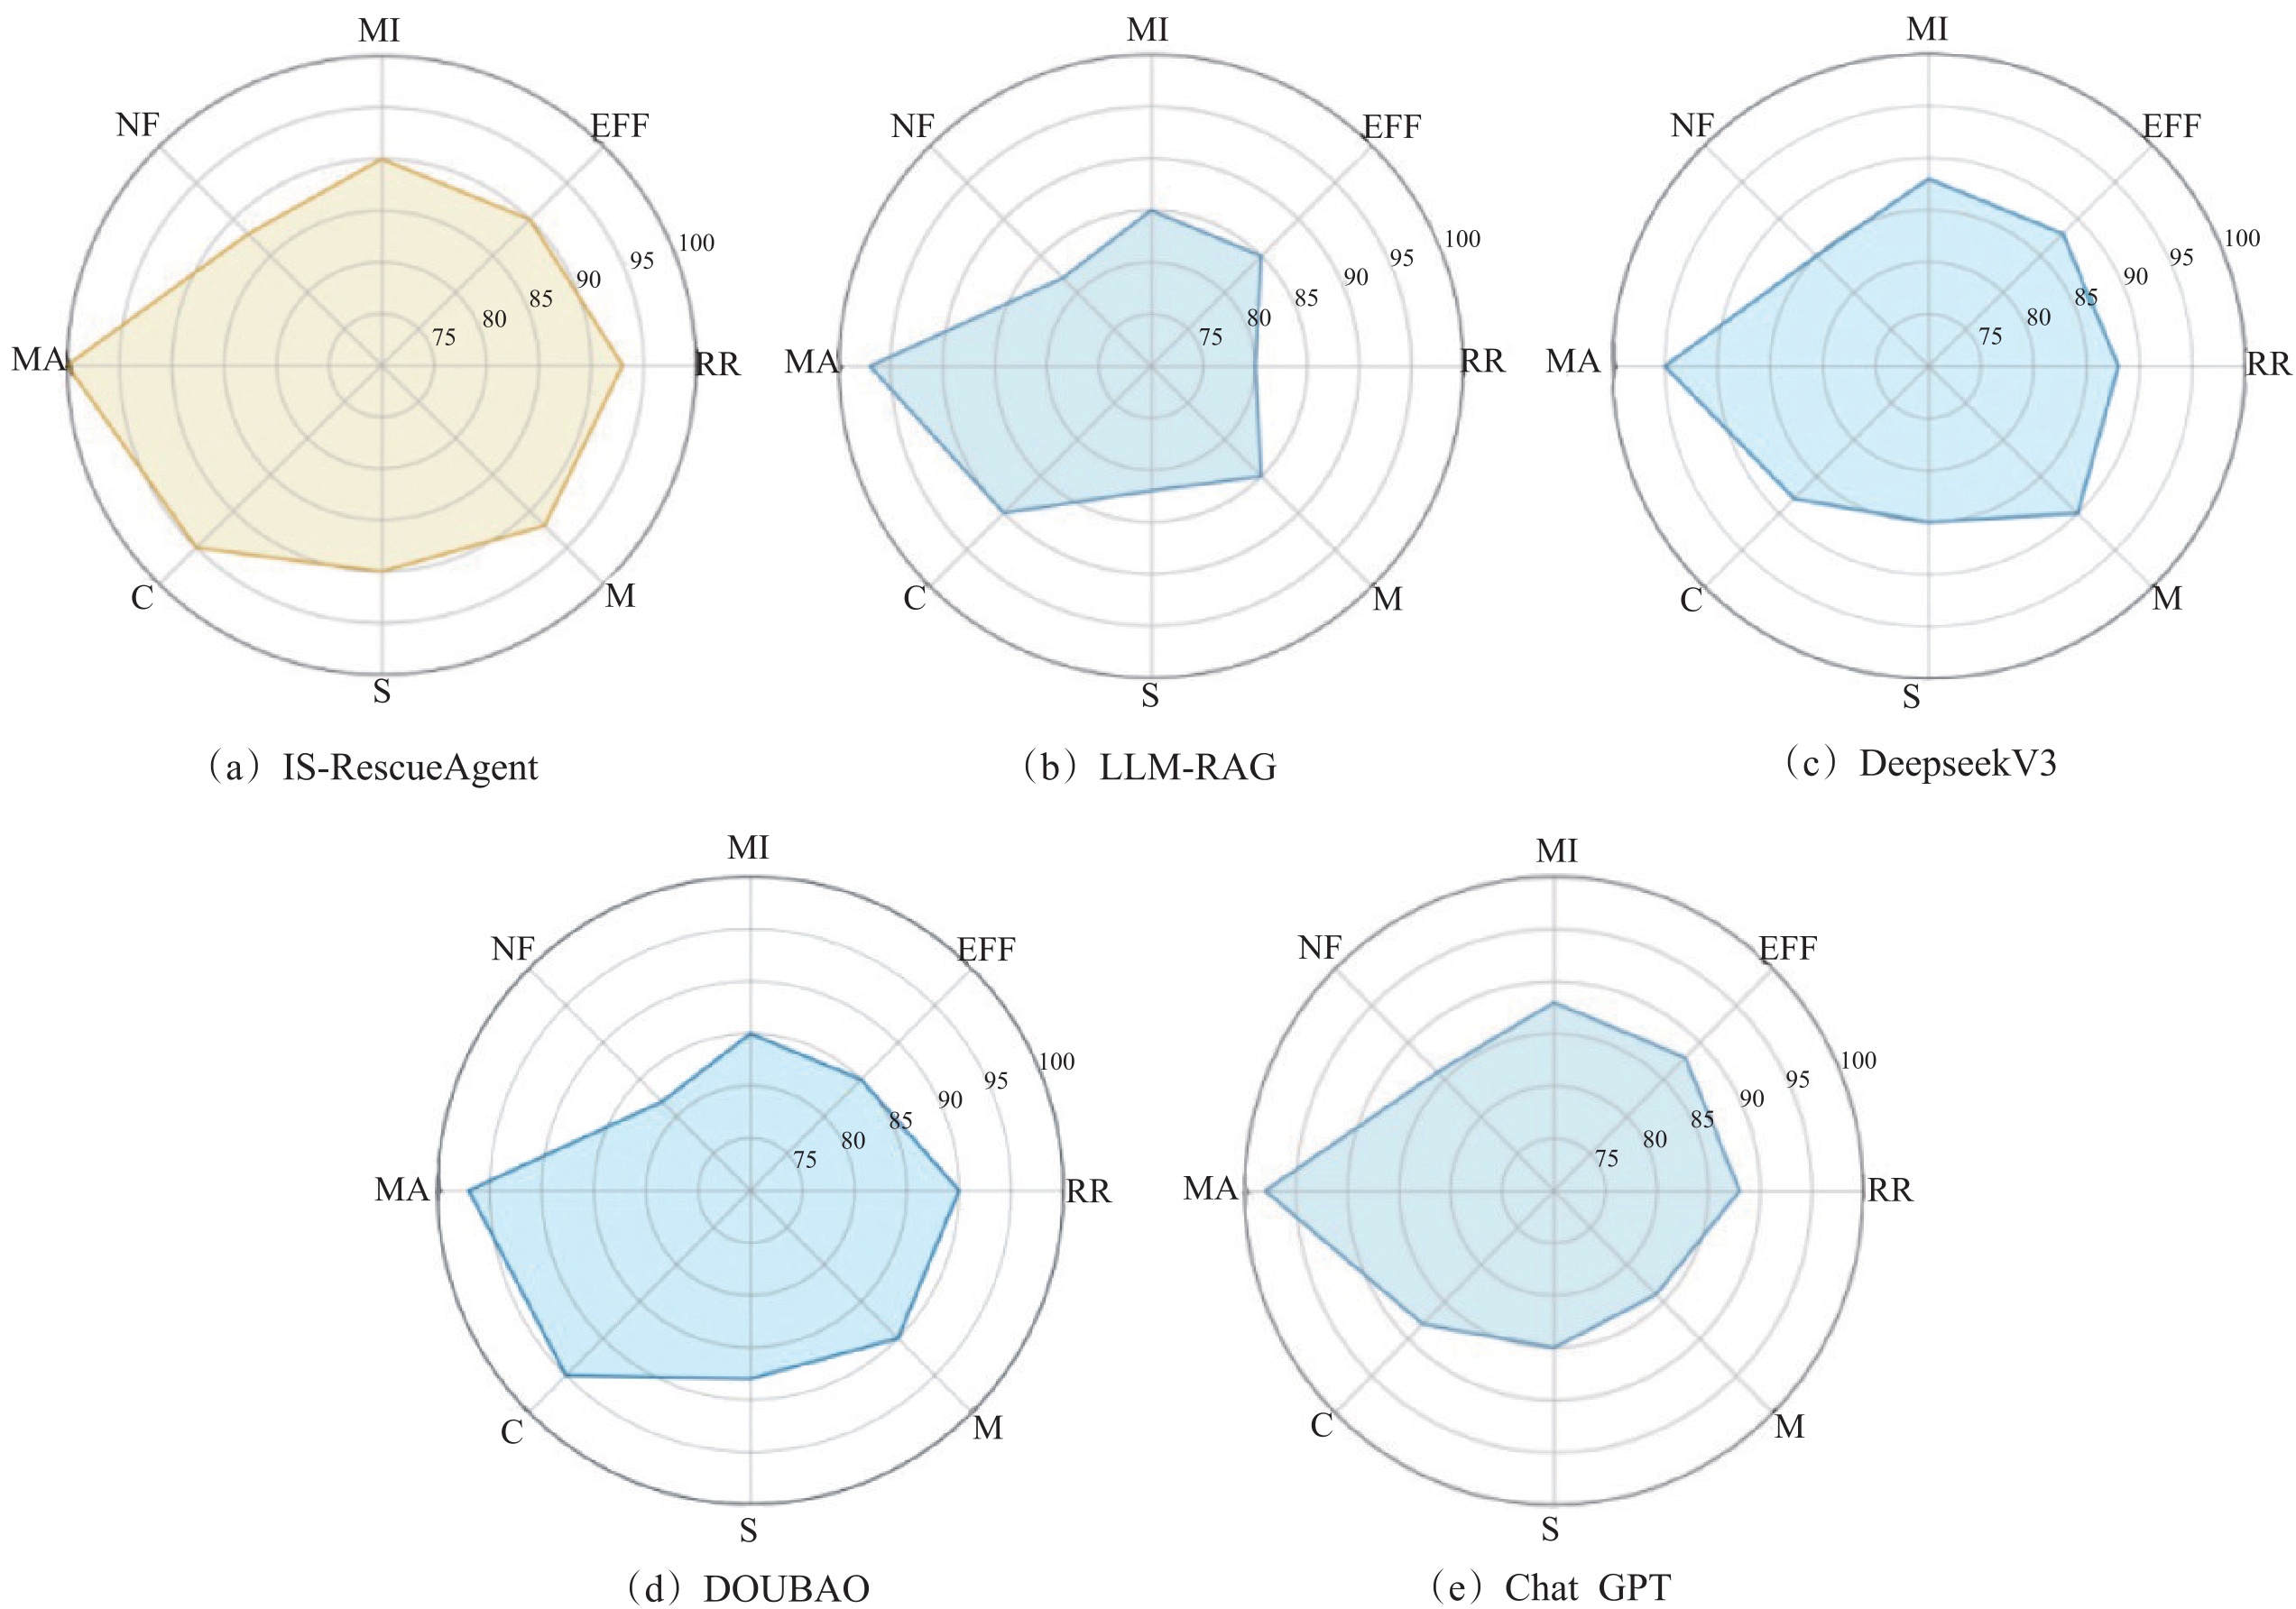
图 8 不同方案准确度的各指标表现折线对比图
Figure 8. Line graphs for comparative sub-metric performance of plan accuracy

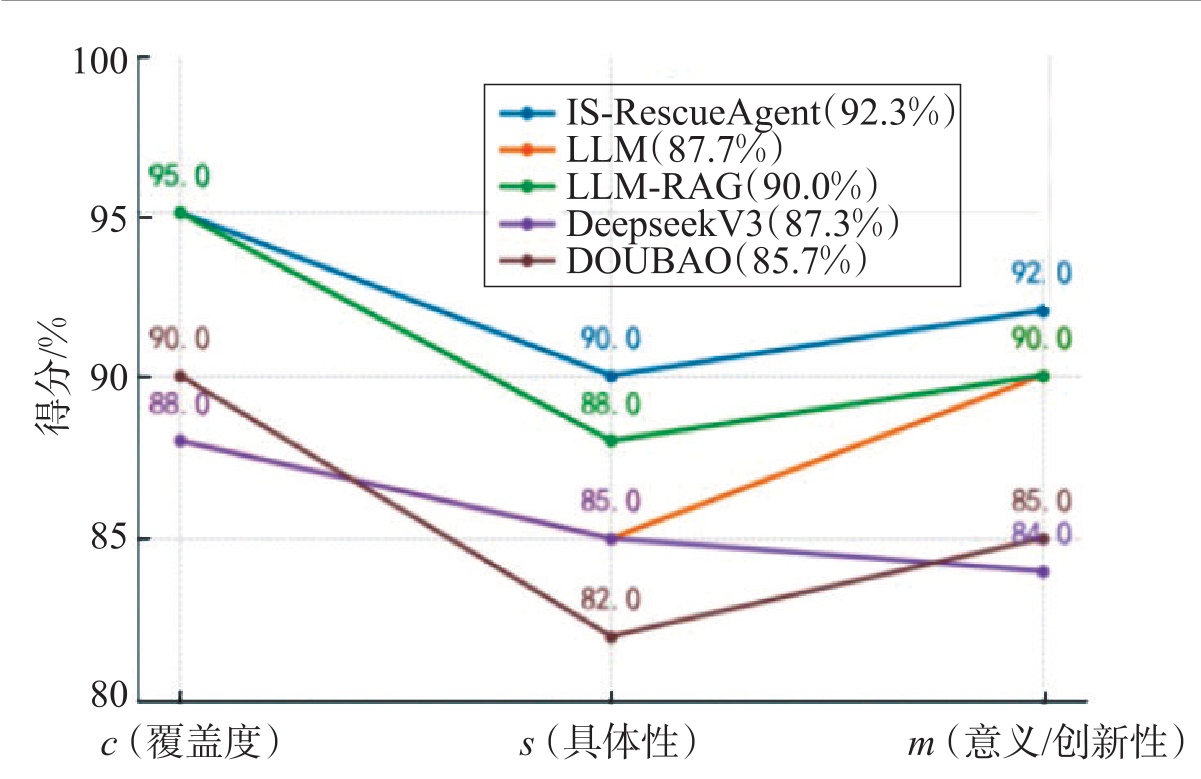
图 9 不同方案合理性与质量的各指标表现折线对比图
Figure 9. Line graphs for comparative sub-metric performance of plan rationality and quality

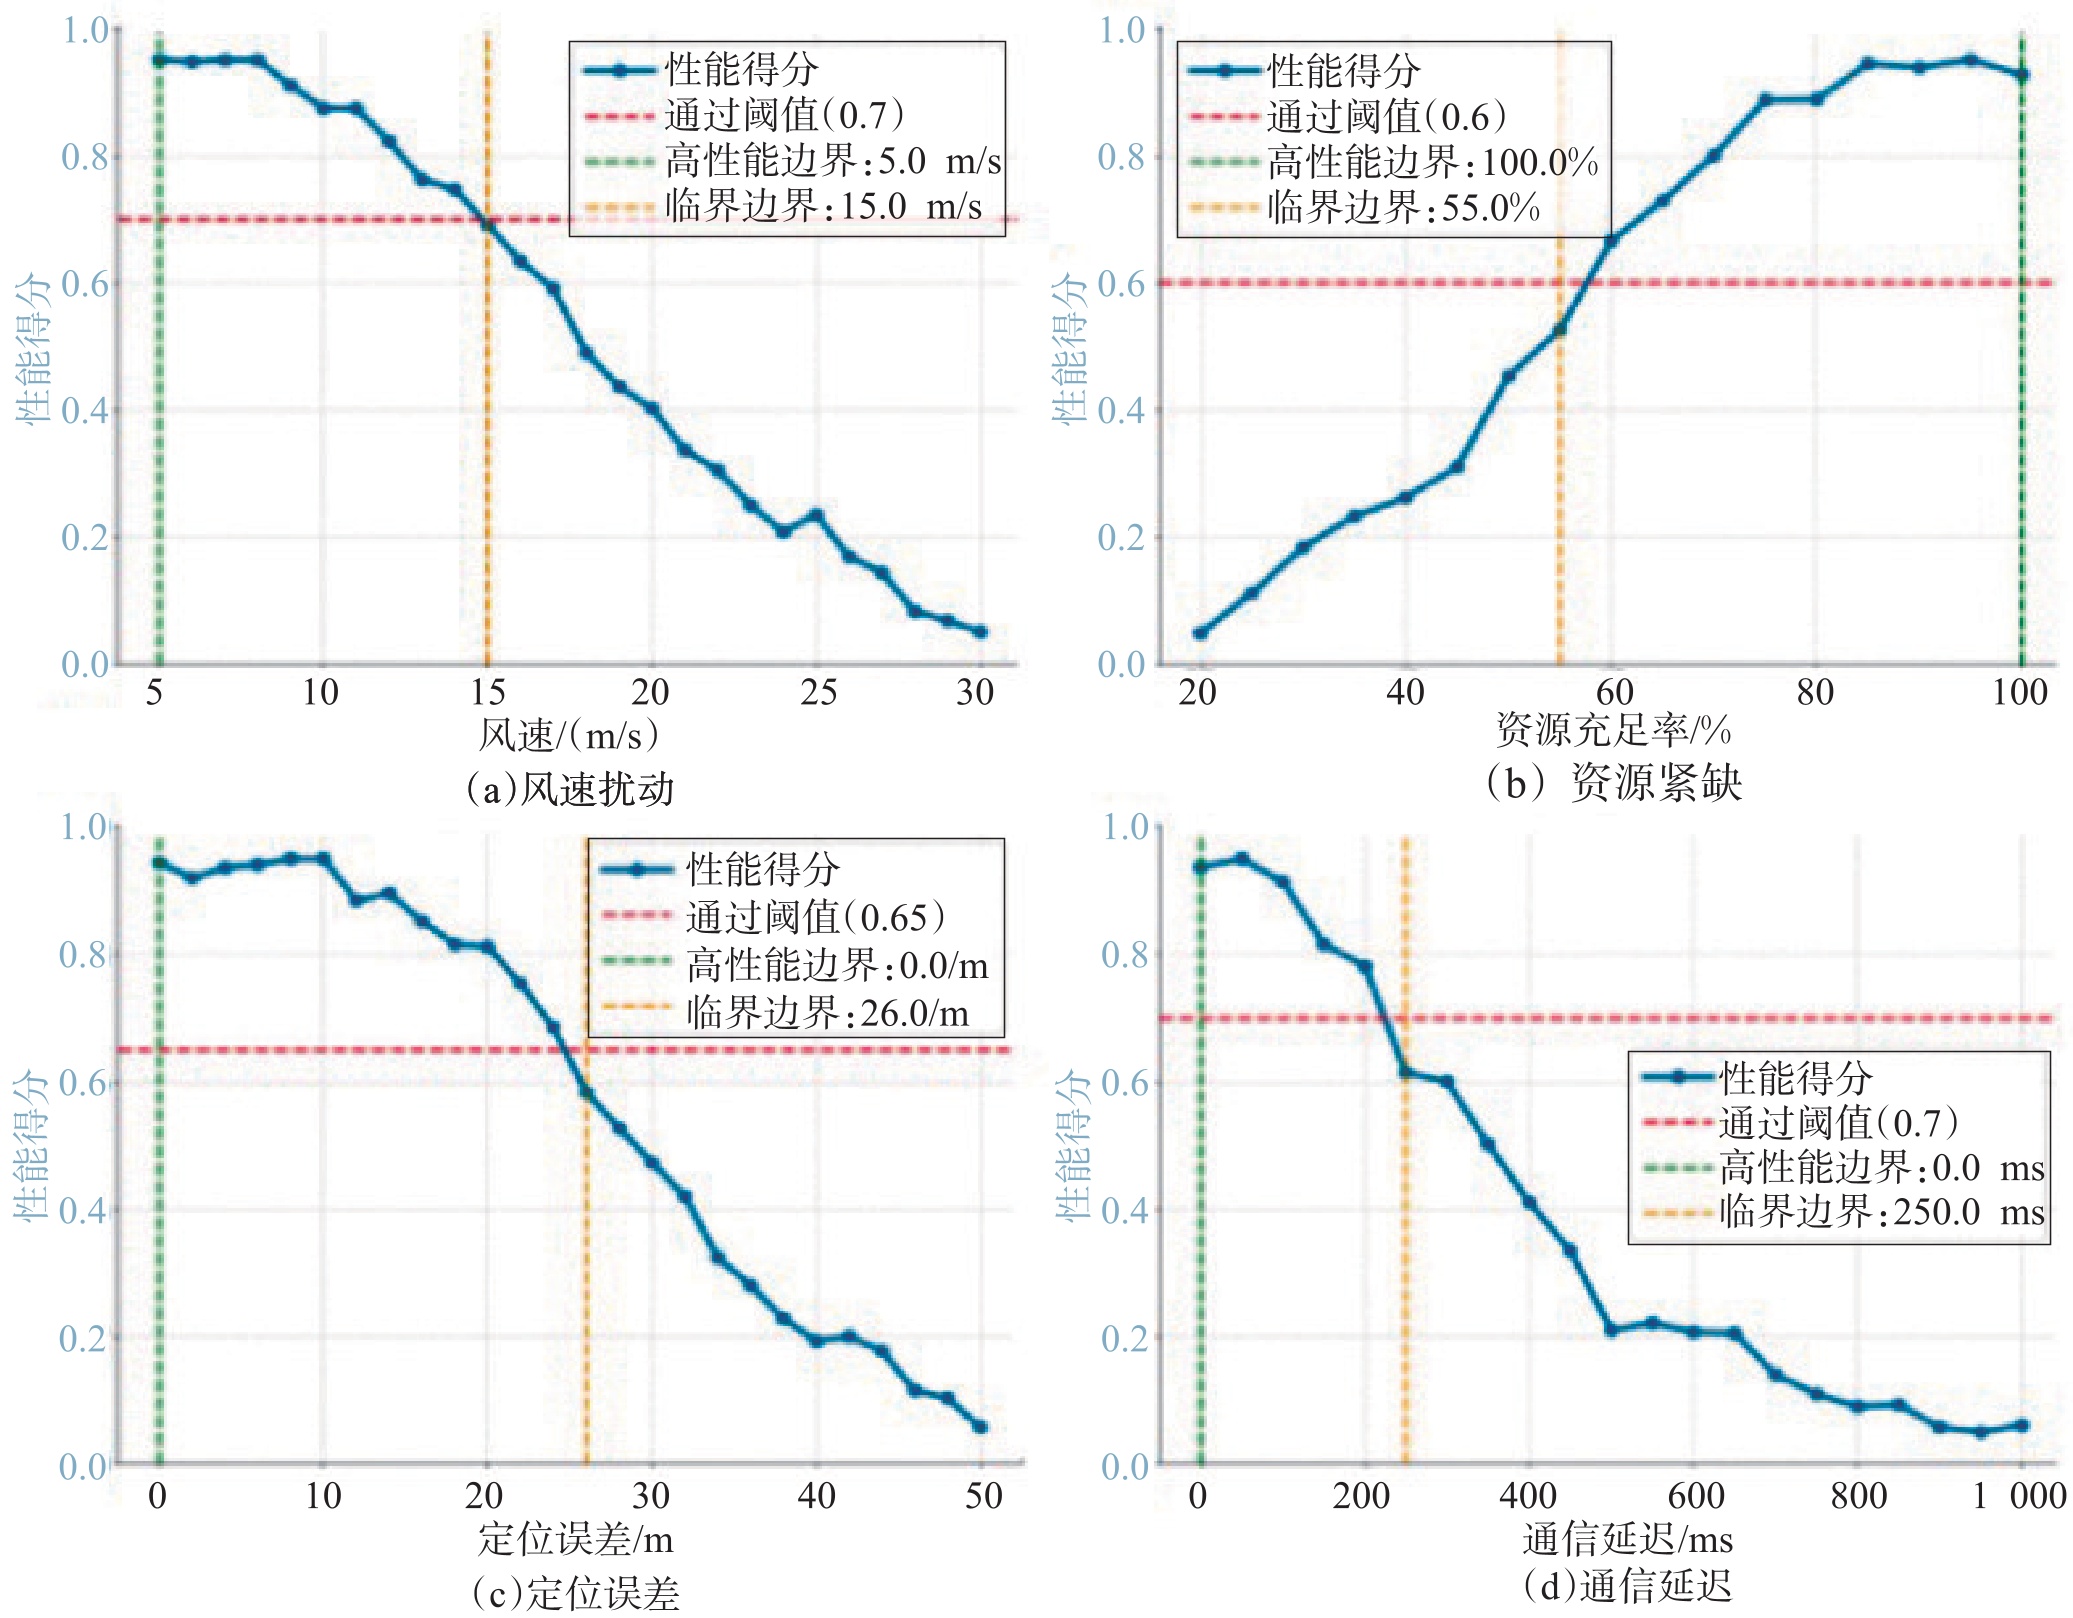
图 10 IS-RescueAgent在典型扰动场景下的鲁棒性边界分析结果
Figure 10. Robustness boundary analysis of IS-RescueAgent under typical disturbance scenarios
表 1 准确度的相关子指标
Table 1. Accuracy-related sub-metrics
子指标 含义 方法 EFF(有效性) 搜救方案整体的执行可行性与逻辑完整性 Prompt: 对以下搜救方案的整体有效性进行评分, 包括其结构完整性、任务可执行性与调度逻辑是否合理 MI(轻微错误) 报告中存在的非核心小错误 Prompt: 请识别以下方案中是否存在轻微错误, 如术语不规范、逻辑不清、重复表述等, 并给出错误比例 NF(非致命错误) 不影响整体执行但可能降低效率的设计缺陷 Prompt: 请检查以下搜集方案中是否存在未覆盖的关键任务步骤、响应延误风险或信息链断裂等非致命问题, 并指出其比例 MA(重大错误) 可能造成搜救失败的关键性失误 Prompt: 请判断以下搜救方案中是否存在可能导致任务失败得关键错误, 指出这些问题的严重程度  下载: 导出CSV
表 2 合理性与质量的相关子指标
Table 2. Rationality and quality-related sub-metrics
子指标 含义 方法 c: 覆盖度(coverage) 是否覆盖所有搜救关键要素 提取关键词模板, 如位置、任务、资源、匹配等完整度 s: 具体性(specificity) 是否包含详细操作建议 使用prompt C要求模型判断“是否具备操作指令、定量建议” m: 意义性(meaningfulness) 是否具备策略深度或创新性 要求模型对方案新颖性打分使用prompt D, 或比较不同版本创新性差异
下载: 导出CSV
表 3 场景设计
Table 3. Scenario design
场景类别 场景名称 核心参数设定 测试目的 基准场景 标准案例信息 作为测试参照 扰动场景A 风速扰动 风速: 从5m/s变到15~25m/s 验证方案在多变气象环境下的路径规划稳定性与抗干扰能力 扰动场景B 资源紧缺 救援资源水平从100%开始, 以20%为步长递减 分析方案在资源紧缺条件下的资源优化分配有效性与任务优先级处理能力 扰动场景C 定位误差 遇险位置参数: 精确定位到引入0~50m定位误差 验证在信息偏差下的容错能力及搜索路径调整有效性 扰动场景D 通信延迟 通信延迟: 0ms到1000ms逐步增加 评估系统在通信受限条件下的决策时效性与多智能体协作可靠性
下载: 导出CSV
表 4 数据集概述表
Table 4. Dataset overview table
数据类别 数据来源 数据规模 时间跨度 更新频率 历史应急救援数据 厦门海事局、东海救助局 5 000+搜救案例、2 000+遇险报告 2017—2024年 静态历史数据 实时环境数据 气象API、船舶AIS、海洋观测站 实时流数据 持续更新 分钟级更新 船舶设备数据 海事设备数据库 10 000+设备数据 长期积累 每日更新
下载: 导出CSV
表 5 IS-RescueAgent与其他模型评估分数比较
Table 5. Comparative analysis of evaluation scores for IS-RescueAgent and competing models
指标维度 IS-RescueAgent LLM LLM-RAG DeepseekV3 DOUBAO Chat GPT 报告相关性/% 93 88 90 88 80 准确度/% 92 89 87 88.5 87.3 合理性与质量/% 92.3 87.7 90 87.3 85.7 综合平均分/% 92.4 88.2 89 87.9 84.3
下载: 导出CSV
表 6 搜救方案准确度的各个子指标评估分数
Table 6. Sub-metric evaluation scores for search and rescue plan accuracy
子指标 IS-RescueAgent LLM LLM-RAG DeepseekV3 DOUBAO Chat GPT EFF(有效性)/% 90.0 88.0 85.0 88.0 85.0 MI(轻微错误率)/% 10.0 12.0 15.0 12.0 15.0 NF(非致命错误率)/% 12.0 15.0 18.0 14.0 18.0 MA(重大错误率)/% 0.0 5.0 3.0 2.0 3.0
下载: 导出CSV
表 7 搜救方案合理性与质量的各个子指标评估分数
Table 7. Sub-metric evaluation scores for search and rescue plan rationality and quality
子指标 IS-RescueAgent LLM LLM-RAG DeepseekV3 DOUBAO Chat GPT c(覆盖度)/% 95.0 88.0 95.0 88.0 90.0 s(具体性)/% 90.0 85.0 88.0 85.0 82.0 m(意义/创新性)/% 92.0 90.0 90.0 84.0 85.0
下载: 导出CSV
-
[1] 陈健, 郑晗晴. 运用无人机提升海事监管效能及搜救应急能力研究[J]. 中国海事, 2025(1): 53-55.CHEN J, ZHENG H Q. Research on improving maritime supervision and emergency SAR capability with UAVs[J]. China Maritime, 2025(1): 53-55. (in Chinese) [2] 李洪, 张大铭, 严晞隽, 等. 面向海洋探测的多源信息融合技术研究及展望[J]. 宇航总体技术, 2021, 5(4): 1-6.LI H, ZHANG D M, YAN X J, et al. Research and prospect of multi-source information fusion technology for ocean exploration [J]. Aerospace System Engineering Technology, 2021, 5(4): 1-6. (in Chinese) [3] MA Q, ZHANG D, WAN C, et al. Multi-objective emergency resources allocation optimization for maritime search and rescue considering accident black-spots[J]. Ocean Engineering, 2022, 261: 112178. doi: 10.1016/j.oceaneng.2022.112178 [4] 龚诚, 刘一飞, 李旭宁. 海上多源数据融合运用体系及关键技术研究[J]. 舰船电子工程, 2024, 44(8): 43-48.GONG C, LIU Y F, LI X N. Research on the application system and key technologies of maritime multi-source data fusion [J]. Ship Electronic Engineering, 2024, 44(8): 43-48. (in Chinese) [5] 刘冬. 基于CBR的库区海事应急救援辅助决策支持系统研究与实现[D]. 武汉: 武汉理工大学, 2017.LIU D. Research and implementation of a CBR-based decision support system for maritime emergency rescue in reservoir areas[D]. Wuhan: Wuhan University of Technology, 2017. (in Chinese) [6] WU J, CHENG L, CHU S, et al. An autonomous coverage path planning algorithm for maritime search and rescue of persons-in-water based on deep reinforcement learning[J]. Ocean Engineering, 2024, 291: 116403. doi: 10.1016/j.oceaneng.2023.116403 [7] 马向宇. 基于多智能体深度强化学习的路径规划算法研究与应用[D]. 扬州: 扬州大学, 2025.MA X Y. Research and application of path planning algorithm based on multi-agent deep reinforcement learning[D]. Yangzhou: Yangzhou University, 2025. (in Chinese) [8] 徐澳, 付昱凯, 彭瑞飞, 等. 基于强化学习的路径规划算法研究[J]. 组合机床与自动化加工技术, 2025(10): 52-57.XU A, FU Y K, PENG R F, et al. Research on path planning algorithm based on reinforcement learning[J]. Modular Machine Tool & Automatic Manufacturing Technique, 2025 (10): 52-57. (in Chinese) [9] 宋哲. 海上搜救船舶与无人机协同路径规划研究[D]. 大连: 大连海事大学, 2024.SONG Z. Research on cooperative path planning of maritime search and rescue vessels and UAVs[D]. Dalian: Dalian Maritime University, 2024. (in Chinese) [10] CHO S W, PARK H J, LEE H, et al. Coverage path planning for multiple unmanned aerial vehicles in maritime search and rescue operations[J]. Computers & Industrial Engineering, 2021, 161: 107612. [11] 李海森, 张阳, 朱建军, 等. 失事目标水中搜寻技术发展现状及趋势[J]. 哈尔滨工程大学学报, 2023, 44(4): 546-553, 579.LI H S, ZHANG Y, ZHU J J, et al. Current status and development trend of underwater search technologies for missing targets[J]. Journal of Harbin Engineering University, 2023, 44(4): 546-553, 579. (in Chinese) [12] 易林生. 海事案例推理中决策支持系统的设计和实现分析[J]. 珠江水运, 2023(2): 98-100.YI L S. Design and implementation analysis of decision support system in maritime case-based reasoning[J]. Pearl River Water Transport, 2023(2): 98-100. (in Chinese) [13] WEI J, WANG X, SCHUURMANS D, et al. Chain-of-thought prompting elicits reasoning in large language models[J]. Advances in Neural Information Processing Systems, 2022, 35: 24824-24837. [14] CHANG Y, WANG X, WANG J, et al. A survey on evaluation of large language models[J]. ACM Transactions on Intelligent Systems and Technology, 2024, 15(3): 1-45. [15] PARK J S, O'BRIEN J, CAI C J, et al. Generative agents: interactive simulacra of human behavior[C]. 36th Annual ACM Symposium on User Interface Software and Technology, San Francisco, USA: ACM, 2023. [16] 张梦雅, 杨晓光, 马成元, 等. 智能网联环境下高速道路交通运行风险分析综述[J]. 交通信息与安全, 2025, 43(2): 137-153.ZHANG M Y, YANG X G, MA C Y, et al. A review of traffic operation risk analysis for expressways under intelligent connected environment[J]. Journal of Transport Information and Safety, 2025, 43(2): 137-153. (in Chinese) [17] 黄昌勤, 钟益华, 王希哲, 等. 从单智能体到多智能体: 大模型智能体支持下的激励型学习活动设计与实证研究[J]. 华东师范大学学报(教育科学版), 2025, 43(5): 44-56.HUANG C Q, ZHONG Y H, WANG X Z, et al. From single-agent to multi-agent: design and empirical study of incentive-based learning activities supported by large model agents[J]. Journal of East China Normal University (Educational Sciences), 2025, 43(5): 44-56. (in Chinese) [18] 李晓冬, 刘小毅, 王鑫鹏. 基于LLM思维链的指挥控制智能体应用设想[J]. 指挥信息系统与技术, 2024, 15(6): 21-27.LI X D, LIU X Y, WANG X P. Application conception of command and control agents based on LLM chain-of-thought[J]. Command Information Systems and Technology, 2024, 15(6): 21-27. (in Chinese) [19] 王明程, 王高开, 李勇男. 基于大模型智能体的安全风险态势感知框架构建[J]. 情报理论与实践, 2024, 47(7): 190-198.WANG M C, WANG G K, LI Y G. Construction of a security risk situation awareness framework based on large model agents[J]. Information Theory and Practice, 2024, 47(7): 190-198. (in Chinese) [20] 袁嵩, 程芬, 程鹏飞, 等. 基于LLM与多智能体协同的医疗对话机制研究[J]. 计算机技术与发展, 2025, 35(X): 1-11.YUAN S, CHENG F, CHENG P F, et al. Research on medical dialogue mechanism based on LLM and multi-agent collaboration[J]. Computer Technology and Development, 2025, 35 (X): 1-11. (in Chinese) [21] 韩资豪. 海上搜救可视化探索[J]. 水上安全, 2023(2): 16-19.HAN Z H. Visual exploration of maritime search and rescue[J]. Water Safety, 2023(2): 16-19. (in Chinese) [22] 朱岿. 海上搜救目标漂移预测模型研究及应用[D]. 武汉: 中国地质大学, 2021.ZHU K. Research and application of drift prediction model for maritime search and rescue targets[D]. Wuhan: China University of Geosciences, 2021. (in Chinese) [23] ES S, JAMES J, ANKE LE, et al. Ragas: automated evaluation of retrieval augmented generation[C]. 18th Conference of the European Chapter of the Association for Computational Linguistics: System Demonstrations, St. Julian's, Malta: Association for Computational Linguistics, 2024. -

 点击查看大图
计量
- 文章访问数: 68
- HTML全文浏览量: 25
- PDF下载量: 11
- 被引次数: 0