

Review of Low-Altitude Route Planning Methods Considering Airspace Environment
-
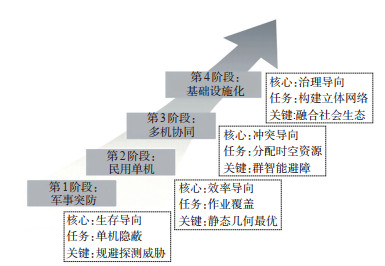
摘要: 低空飞行活动的增加及应用场景的拓展,对航路规划的安全性、环境适应性和多机运行组织提出了更高要求。围绕复杂空域环境下的低空航路规划,以任务演进、影响因素、规划算法3个层面系统梳理研究进展,为航路设计与运行条件确定提供参考。根据规划对象的拓展过程,将低空航路规划划分为军事突防、民用单机、多机协同和基础设施网络化4个阶段,并归纳各阶段的核心约束与优化目标。在影响因素方面,从地面环境、空域管理、飞行需求和社会生态条件出发,归纳各类因素的建模方式,并将其作用区分为限制航路使用资格的约束条件与影响方案比较的代价因素。在规划算法方面: ①面向复杂空间中的航路可执行性,采用势场引导、自适应采样、运动学约束改善路径搜索与航段连接,通过规划与跟踪一体化、导航不确定性建模,将执行过程与碰撞风险纳入规划;②面向气象变化下的安全与效率需求,采用地形风场建模、结冰风险约束和分布鲁棒优化,分别降低飞行代价、限定可行路径和减少配送延误;③面向多机共享空域,采用网络与需求联合设计、准动态交通分配,以及战略与战术联合冲突管理,将规划对象由单次任务扩展至航路网络及其时空资源配置。研究表明,低空航路规划算法已由几何避障发展至运动学适配、导航风险评价和网络交通分配,但相关管理规则难以直接纳入规划模型,环境指标尚未形成分级使用标准,算法验证多停留于单次任务,制约公共航路网络的持续运行。未来,面向航路安全使用需求,开展异质飞行器的安全裕度与运行条件研究,完善气象预测不确定性下的航路调整与任务重排方法;面向航路持续运行需求,研究执行偏差反馈下的容量配置与备选通道设计,协调正常运行效率与异常恢复能力。Abstract: The growth of low-altitude flight activities and the expansion of application scenarios place increasing demands on the safety, environmental adaptability, and coordination of multiple aircraft in route planning. Focusing on low-altitude route planning in complex airspace environments, this review systematically summarizes research progress from three perspectives: task evolution, influencing factors, and planning algorithms, so as to inform route design and the specification of operating conditions. According to the expansion of planning objects, the evolution of low-altitude route planning is divided into four stages, i.e., military penetration, civil single-aircraft, multi-aircraft coordination, and infrastructure networking, and the core constraints and optimization objectives of each stage are summarized. Regarding influencing factors, ground environments, airspace management, flight demand, and socio-ecological conditions are examined to summarize their modeling approaches, and their effects are divided intoThe growth of low-altitude flight activities and the expansion of application scenarios place increasing demands on the safety, environmental adaptability, and coordination of multiple aircraft in route planning. Focusing on low-altitude route planning in complex airspace environments, this review systematically summarizes research progress from three perspectives: task evolution, influencing factors, and planning algorithms, so as to inform route design and the specification of operating conditions. According to the expansion of planning objects, the evolution of low-altitude route planning is divided into four stages, i.e., military penetration, civil single-aircraft, multi-aircraft coordination, and infrastructure networking, and the core constraints and optimization objectives of each stage are summarized. Regarding influencing factors, ground environments, airspace management, flight demand, and socio-ecological conditions are examined to summarize their modeling approaches, and their effects are divided into constraints on route eligibility and cost factors affecting scheme comparison. Regarding planning algorithms: ①To improve trajectory feasibility in complex environments, potential-field guidance, adaptive sampling, and kinematic constraints are incorporated to improve path search and segment connection, while integrated planning and tracking and navigation uncertainty modeling bring trajectory execution and collision risk into the planning process. ②To address safety and efficiency under changing weather conditions, terrain and wind-field modeling, icing-risk constraints, and distributionally robust optimization are used to reduce flight costs, identify feasible trajectories, and mitigate delivery delays, respectively. ③To support multiple aircraft sharing airspace, integrated network design and demand modeling, quasi-dynamic traffic assignment, and combined strategic and tactical conflict management extend planning from individual missions to route networks and the allocation of spatial and temporal resources. The re sults indicate that existing planning algorithms have advanced from geometric obstacle avoidance to kinematic adap tation, navigation risk assessment, and network traffic assignment; however, management rules can hardly enter planning models directly, environmental indicators have not yet been converted into tiered route-use standards, and algorithm validation mostly remains at the level of single missions, which restricts the sustainable operation of public route networks. In the future, research on safety margins and operating conditions of heterogeneous aircraft should be conducted, and route adjustment and mission rescheduling under weather forecast uncertainty should be improved to support safe route use; capacity allocation incorporating feedback on trajectory execution deviations and alternative corridor design should also be investigated to balance operational efficiency under normal conditions with recovery capability following disruptions.
-

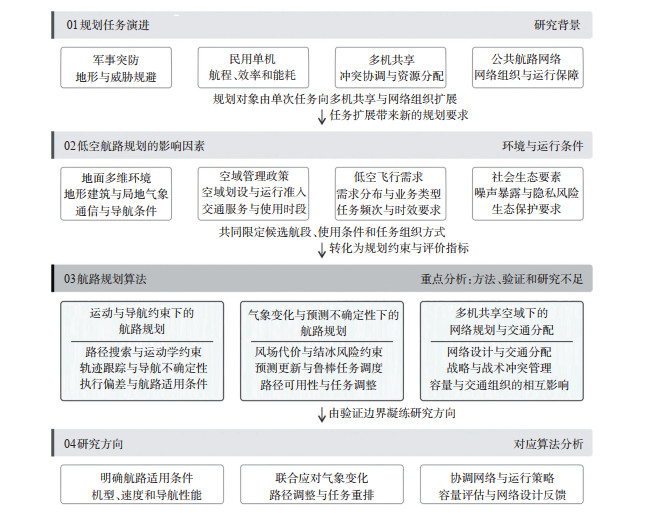
图 1 考虑空域环境的低空航路规划研究方法综述框架
Figure 1. Review framework of research methods for low-altitude route planning considering airspace environment

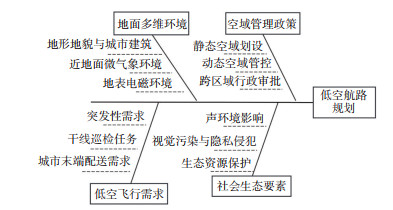
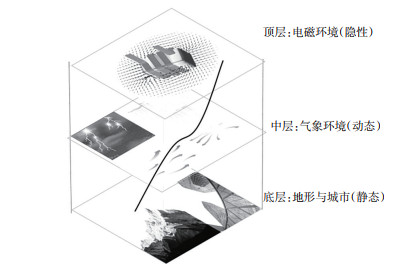
图 4 地面多维环境的物理约束分析图
Figure 4. Analysis of physical constraints in multi-dimensional ground environments
表 1 典型空域管理框架及其对航路使用的约束
Table 1. Typical airspace management frameworks and their constraints on route use
 下载: 导出CSV
表 2 运动与导航约束下的航路规划方法比较
Table 2. Comparison of route planning methods under motion and navigation constraints
下载: 导出CSV
表 3 多机共享空域下航路网络规划的代表性研究
Table 3. Representative studies on air route network planning in multi-aircraft shared airspace
下载: 导出CSV
表 4 4种交通分配方式的比较
Table 4. Comparison of four traffic assignment schemes
分配方式 决策范围 优化效果 计算可处理性 顺序延误 按到达顺序逐个任务安排, 后续任务承担延误 低 高 顺序延误与改航 按顺序安排, 冲突任务可改用备选路径 中 较高 全量优化 全部任务的起飞时刻与路径联合优化 高 低 分批优化 任务分批, 批内联合优化 较高 较高
下载: 导出CSV
-
[1] 廖小罕, 徐晨晨, 叶虎平, 等. 无人机应用发展关键基础设施与低空公共航路网规划[J]. 中国科学院院刊, 2022, 37(7): 977-988.LIAO X H, XU C C, YE H P, et al. Key infrastructure for UAV application development and planning of low-altitude public air route network[J]. Bulletin of the Chinese Academy of Sciences, 2022, 37(7): 977-988. (in Chinese) [2] 赵嶷飞, 李仲明, 任新惠. 城市场景无人机物流航线规划方法综述[J]. 南京航空航天大学学报(自然科学版), 2025, 57 (6): 1013-1025.ZHAO Y F, LI Z M, REN X H. Review on logistics air route planning methods for unmanned aerial vehicles in urban scenarios[J]. Journal of Nanjing University of Aeronautics & Astronautics, 2025, 57(6): 1013-1025. (in Chinese) [3] 郑昌文, 严平, 丁明理. 飞行器低空突防航迹规划综述[J]. 系统工程与电子技术, 2005, 27(4): 677-682.ZHENG C W, YAN P, DING M L. Review of low-altitude penetration route planning for aircraft[J]. Systems Engineering and Electronics, 2005, 27(4): 677-682. (in Chinese) [4] XU W Y, YU X B, XUE X Y. A binary gridding path-planning method for plant-protecting UAVs on irregular fields[J]. Journal of Integrative Agriculture, 2023, 22(9): 2796-2809. doi: 10.1016/j.jia.2023.02.029 [5] 于少猛, 闫铭, 王鹏飞, 等. 丘陵山地果园植保无人机三维路径规划[J]. 浙江大学学报(工学版), 2025, 59(3): 635-642.YU S M, YAN M, WANG P F, et al. 3D path planning of plant protection UAVs in hilly mountainous orchards[J]. Journal of Zhejiang University(Engineering Science), 2025, 59 (3): 635-642. (in Chinese) [6] 沈跃, 张凌飞, 沈亚运, 等. 基于相邻争夺算法的无人机多架次植保作业路径规划[J]. 农业工程学报, 2024, 40(16): 44-51.SHEN Y, ZHANG L F, SHEN Y Y, et al. Path planning for the multiple drones plant protection operations of UAV based on adjacent contention algorithm[J]. Transactions of the Chinese Society of Agricultural Engineering, 2024, 40(16): 44-51. (in Chinese) [7] KYRIAKAKIS N A, ARONIS S, MARINAKI M, et al. A GRASP/VND algorithm for the energy minimizing drone routing problem with pickups and deliveries[J]. Computers & Industrial Engineering, 2023, 182: 109340. [8] QUAN Q, GAO Y, BAI C. Distributed control for a robotic swarm to pass through a curve virtual tube[J]. Robotics and Autonomous Systems, 2023, 162: 104368. doi: 10.1016/j.robot.2023.104368 [9] WU Y, LOW K H, HU X. Trajectory-based flight scheduling for AirMetro in urban environments by conflict resolution[J]. Transportation Research Part C: Emerging Technologies, 2021, 131: 103355. doi: 10.1016/j.trc.2021.103355 [10] 廖小罕, 屈文秋, 徐晨晨, 等. 城市空中交通及其新型基础设施低空公共航路研究综述[J]. 航空学报, 2023, 44(24): 6-34.LIAO X H, QU W Q, XU C C, et al. A review of urban air mobility and its new infrastructure low-altitude public routes[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(24): 6-34. (in Chinese) [11] 孙卫国, 吕人力, 李凌威, 等. 低空经济面临的机遇、挑战与城市空中交通规划展望[J]. 城市交通, 2025, 23(2): 13-19, 127.SUN W G, LYU R L, LI L W, et al. Opportunities and challenges for low-altitude economy and future prospects of urban air mobility planning[J]. Urban Transport of China, 2025, 23(2): 13-19, 127. (in Chinese) [12] OH S, YOON Y. Urban drone operations: a data-centric and comprehensive assessment of urban airspace with a Pareto-based approach[J]. Transportation Research Part A: Policy and Practice, 2024, 182: 104034. doi: 10.1016/j.tra.2024.104034 [13] HE H B, YE H P, XU C C, et al. Urban low-altitude airspace resources: integrating risk and accessibility through fine-grained analysis[J]. Cities, 2026, 175: 107190. doi: 10.1016/j.cities.2026.107190 [14] DÍEZ-GONZÁLEZ J, FERRERO-GUILLÉN R, VERDE P, et al. Analysis of synchronous localization systems for UAVs urban applications[J]. Neurocomputing, 2024, 564: 126969. doi: 10.1016/j.neucom.2023.126969 [15] GAO M, HUGENHOLTZ C H, FOX T A, et al. Weather constraints on global drone flyability[J]. Scientific Reports, 2021, 11: 12092. doi: 10.1038/s41598-021-91325-w [16] VIET P Q, ROMERO D. Path planning for aerial relays via probabilistic roadmaps[J]. IEEE Transactions on Communications, 2026, 74: 4251-4266. doi: 10.1109/TCOMM.2026.3658381 [17] CHAN Y Y, NG K K H, LEE C K M, et al. Wind dynamic and energy-efficiency path planning for unmanned aerial vehicles in the lower-level airspace and urban air mobility context[J]. Sustainable Energy Technologies and Assessments, 2023, 57: 103202. doi: 10.1016/j.seta.2023.103202 [18] PATIL A, GARCÍA-SÁNCHEZ C. Quantifying the impact of urban geometric detail for urban air mobility risk forecasting[J]. Sustainable Cities and Society, 2025, 132: 106750. doi: 10.1016/j.scs.2025.106750 [19] DAI Y W, ZHU F Y, TU W L, et al. Urban air mobility in the built environment: a review of aerodynamic interactions, thermal effects, and simulation challenges[J]. Sustainable Cities and Society, 2025, 133: 106853. doi: 10.1016/j.scs.2025.106853 [20] 中国民用航空局. 关于发布《国家空域基础分类方法》的通知[EB/OL]. (2023-12-21)[2025-07-31]. https://www.caac.gov.cn/.XXGK/XXGK/TZTG/202312/t20231221_222397.html .Civil Aviation Administration of China. Notice on issuing the basic classification method of national airspace[EB/OL]. (2023-12-21)[2025-07-31].https://www.caac.gov.cn/XXGK/XXGK/TZTG/202312/t20231221_222397.html . (in Chinese)[21] 中华人民共和国交通运输部. 民用无人驾驶航空器运行安全管理规则: 中华人民共和国交通运输部令2024年第1号[EB/OL]. (2024-01-03)[2025-07-31]. https://xxgk.mot.gov.cn/2020/jigou/fgs/202401/t20240103_3980642.html .Ministry of Transport of the People's Republic of China. Operation safety management rules for civil unmanned aircraft: Ministry of Transport Order No. 1 of 2024[EB/OL]. (2024-01- 03)[2025-07-31].https://xxgk.mot.gov.cn/2020/jigou/fgs/202401/t20240103_3980642.html . (in Chinese)[22] FEDERAL AVIATION ADMINISTRATION. Unmanned aircraft systems(UAS)traffic management(UTM)implementation plan[R/OL]. Washington, D.C. : Federal Aviation Administration, 2023. [2026-09-09]. https://www.faa.gov/sites/faa.gov/files/PL_115-254_Sec376_UAS_Traffic_Management.pdf .[23] EUROPEAN UNION AVIATION SAFETY AGENCY. Easy access rules for U-space(Regulation(EU)2021/664)[EB/OL]. Cologne, Germany: European Union Aviation Safety Agency. (2024-05-29)[2026-09-09]. https://www.easa.europa.eu/en/document-library/easy-access-rules/easy-access-rules-u-spaceregulation-eu-2021664 .[24] BIEHLE T. Urban dimension of U-space: local planning considerations for drone integration[J]. Drones, 2025, 9(11): 744. doi: 10.3390/drones9110744 [25] DECKER C, CHIAMBARETTO P. Economic policy choices and trade-offs for unmanned aircraft systems traffic management (UTM): insights from Europe and the United States[J]. Transportation Research Part A: Policy and Practice, 2022, 157: 40-58. doi: 10.1016/j.tra.2022.01.006 [26] 肖作鹏, 张伟聪, 李祎杨, 等. 低空无人机配送的空地协同组织特征及挑战: 以深圳市为例[J]. 资源科学, 2025, 47 (8): 1663-1674.XIAO Z P, ZHANG W C, LI Y Y, et al. Characteristics and challenges of air-ground coordination for low-altitude drone delivery: a case study of Shenzhen[J]. Resources Science, 2025, 47(8): 1663-1674. (in Chinese) [27] 黄建中, 何嘉雯, 张伟聪, 等. 城市低空规划: 地空协同的要素、实现路径和规划响应[J]. 城市规划学刊, 2025(5): 14-22.HUANG J Z, HE J W, ZHANG W C, et al. Urban low-altitude planning: elements, implementation pathways, and planning strategies for ground-air coordination[J]. Urban Planning Forum, 2025(5): 14-22. (in Chinese) [28] 任新惠, 芮钰琪. 基于配送服务模式及路径策略的物流无人机调度模型[J]. 北京交通大学学报, 2024, 48(3): 1-14.REN X H, RUI Y Q. Logistics drone scheduling model based on delivery service modes and routing strategies[J]. Journal of Beijing Jiaotong University, 2024, 48(3): 1-14. (in Chinese) [29] CHOUDHURY S, SOLOVEY K, KOCHENDERFER M J, et al. Efficient large-scale multi-drone delivery using transit networks[J]. Journal of Artificial Intelligence Research, 2021, 70: 757-788. doi: 10.1613/jair.1.12450 [30] DAYARIAN I, SAVELSBERGH M, CLARKE J P. Same-day delivery with drone resupply[J]. Transportation Science, 2020, 54(1): 229-249. doi: 10.1287/trsc.2019.0944 [31] 任洪涛. 低空智联飞行器噪声污染侵权责任研究[J]. 法学杂志, 2025, 46(5): 110-124.REN H T. Research on tort liability for noise pollution of low-altitude intelligent connected aircraft[J]. Law Science Magazine, 2025, 46(5): 110-124. (in Chinese) [32] 朱正余. 低空经济与城市治理: 噪声污染、隐私侵犯与公共空间占用的冲突与调适[J]. 湖南科技大学学报(社会科学版), 2025, 28(3): 177-184.ZHU Z Y. Low-altitude economy and urban governance: conflicts and adaptation of noise pollution, privacy infringement and occupation of public space[J]. Journal of Hunan University of Science and Technology (Social Science Edition), 2025, 28(3): 177-184. (in Chinese) [33] KAWAI C, JÄGGI J, GEORGIOU F, et al. Short-term noise annoyance towards drones and other transportation noise sources: a laboratory study[J]. The Journal of the Acoustical Society of America, 2024, 156(4): 2578-2595. doi: 10.1121/10.0032386 [34] 付翠英, 张轶夫. 低空安全治理中的隐私保护: 风险、问题及对策[J]. 中国信息安全, 2025(10): 23-26.FU C Y, ZHANG Y F. Privacy protection in low-altitude safety governance: risks, problems and countermeasures[J]. China Information Security, 2025(10): 23-26. (in Chinese) [35] MULERO-PÁZMÁNY M, JENNI-EIERMANN S, STREBEL N, et al. Unmanned aircraft systems as a new source of disturbance for wildlife: a systematic review[J]. PLOS ONE, 2017, 12(6): e0178448. doi: 10.1371/journal.pone.0178448 [36] 刘文倩, 单梁, 张伟龙, 等. 复杂环境下基于改进Informed RRT的无人机路径规划算法[J]. 上海交通大学学报, 2024, 58(4): 511-524.LIU W Q, SHAN L, ZHANG W L, et al. UAV path planning algorithm based on improved Informed RRT in complex environment[J]. Journal of Shanghai Jiao Tong University, 2024, 58(4): 511-524. (in Chinese) [37] 杨毅, 冯彦辉, 梁月乾. 基于Dubins-RRT算法的无人机集群密集障碍物区域覆盖航路规划[J]. 战术导弹技术, 2024 (5): 83-98.YANG Y, FENG Y H, LIANG Y Q. Coverage route planning of UAV swarm in dense obstacle region based on Dubins-RRT algorithm[J]. Tactical Missile Technology, 2024 (5): 83-98. (in Chinese) [38] WANG B, ZHANG Y M, ZHANG W. Integrated path planning and trajectory tracking control for quadrotor UAVs with obstacle avoidance in the presence of environmental and systematic uncertainties: theory and experiment[J]. Aerospace Science and Technology, 2022, 120: 107277. doi: 10.1016/j.ast.2021.107277 [39] DELAMER J A, WATANABE Y, CHANEL C P C. Safe path planning for UAV urban operation under GNSS signal occlusion risk[J]. Robotics and Autonomous Systems, 2021, 142: 103800. doi: 10.1016/j.robot.2021.103800 [40] 胡小兵, 杨常澍, 周隽. 复杂城市环境下无人机路网模型研究[J]. 交通运输系统工程与信息, 2023, 23(4): 251-261.HU X B, YANG C S, ZHOU J. Route network modeling for unmanned aerial vehicle in complex urban environment[J]. Journal of Transportation Systems Engineering and Information Technology, 2023, 23(4): 251-261. (in Chinese) [41] 常绪成, 张心慧, 党帅龙, 等. 面向无人机路径规划的A*-DWA分层融合算法[J]. 现代防御技术, 2026, 54(1): 14-29.CHANG X C, ZHANG X H, DANG S L, et al. Research on UAV path planning based on an improved A*-DWA hierarchical fusion algorithm[J]. Modern Defence Technology, 2026, 54(1): 14-29. (in Chinese) [42] 陈佳, 张珂, 杜英森, 等. 基于改进势场法的多无人机避碰控制方法[J]. 探测与控制学报, 2024, 46(4): 93-100.CHEN J, ZHANG K, DU Y S, et al. Improved potential field method for multi-UAV collision avoidance control[J]. Journal of Detection & Control, 2024, 46(4): 93-100. (in Chinese) [43] 姚胤博, 许睿, 徐悦, 等. 卫星导航干扰源无人机定位观测路径规划方法[J]. 全球定位系统, 2024, 49(6): 72-83.YAO Y B, XU R, XU Y, et al. Method for configuring observation point paths for UAV satellite navigation interference source localization[J]. GNSS World of China, 2024, 49(6): 72-83. (in Chinese) [44] 梁丽月, 余道杰, 杜剑平, 等. 基于多模态特征融合和粒子群优化的无人机地形匹配算法[J]. 强激光与粒子束, 2025, 37(11): 113023.LIANG L Y, YU D J, DU J P, et al. Unmanned aerial vehicle terrain matching algorithm based on multimodal feature fusion and particle swarm optimization[J]. High Power Laser and Particle Beams, 2025, 37(11): 113023. (in Chinese) [45] 唐俊超, 胡春鹤. 三维地形风场环境下无人机全覆盖路径规划[J]. 系统工程与电子技术, 2025, 47(7): 2349-2356.TANG J C, HU C H. Complete coverage path planning for UAVs in 3D terrain and wind field environment[J]. Systems Engineering and Electronics, 2025, 47(7): 2349-2356. (in Chinese) [46] 赵嶷飞, 谷瑞嘉, 任新惠. 考虑城市低空风场的小型无人机路径规划方法[J]. 北京航空航天大学学报, 2026, 52(6): 1777-1788.ZHAO Y F, GU R J, REN X H. Small unmanned aerial vehicles path planning method considering urban low-altitude wind fields[J]. Journal of Beijing University of Aeronautics and Astronautics, 2026, 52(6): 1777-1788. (in Chinese) [47] 郭琪磊, 桑为民, 牛俊杰, 等. 复杂气象条件下考虑结冰风险的无人机飞行策略[J]. 航空学报, 2023, 44(1): 627518.GUO Q L, SANG W M, NIU J J, et al. UAV flight strategy considering icing risk under complex meteorological conditions[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44 (1): 627518. (in Chinese) [48] CHENG C, ADULYASAK Y, ROUSSEAU L M. Robust drone delivery with weather information[J]. Manufacturing & Service Operations Management, 2024, 26(4): 1402-1421. [49] 宋璐璐, 邓超, 范莎. 基于事件触发的时变风场下无人机实时路径重规划策略[J]. 控制与决策, 2026, 41(3): 835-844.SONG L L, DENG C, FAN S. Real-time path replanning strategy for UAVs in time-varying wind fields based on event-triggered mechanism[J]. Control and Decision, 2026, 41(3): 835-844. (in Chinese) [50] JUNG H, KIM J. Drone scheduling model for delivering small parcels to remote islands considering wind direction and speed[J]. Computers & Industrial Engineering, 2022, 163: 107784. [51] WU Z, ZHANG Y. Integrated network design and demand forecast for on-demand urban air mobility[J]. Engineering, 2021, 7(4): 473-487. doi: 10.1016/j.eng.2020.11.007 [52] LI A, HANSEN M, ZOU B. Traffic management and resource allocation for UAV-based parcel delivery in low-altitude urban space[J]. Transportation Research Part C: Emerging Technologies, 2022, 143: 103808. doi: 10.1016/j.trc.2022.103808 [53] WANG Z, DELAHAYE D, FARGES J L, et al. A quasi-dynamic air traffic assignment model for mitigating air traffic complexity and congestion for high-density UAM operations[J]. Transportation Research Part C: Emerging Technologies, 2023, 154: 104279. doi: 10.1016/j.trc.2023.104279 [54] 全权, 李刚, 柏艺琴, 等. 低空无人机交通管理概览与建议[J]. 航空学报, 2020, 41(1): 023238.QUAN Q, LI G, BAI Y Q, et al. Low altitude UAV traffic management: an introductory overview and proposal[J]. Acta Aeronautica et Astronautica Sinica, 2020, 41(1): 023238. (in Chinese) [55] SUNIL E, ELLERBROEK J, HOEKSTRA J, et al. An analysis of decentralized airspace structure and capacity using fast-time simulations[J]. Journal of Guidance, Control, and Dynamics, 2017, 40(1): 38-51. doi: 10.2514/1.G000528 [56] BADEA C A, ELLERBROEK J, VIDOSAVLJEVIĆ A, et al. Resilient conflict detection and resolution for high-uncertainty constrained urban airspace operations[J]. Transportation Research Interdisciplinary Perspectives, 2025, 34: 101700. doi: 10.1016/j.trip.2025.101700 [57] CHEN S, EVANS A D, BRITTAIN M, et al. Integrated conflict management for UAM with strategic demand capacity balancing and learning-based tactical deconfliction[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25 (8): 10049-10061. doi: 10.1109/TITS.2024.3351049 [58] 杨剑挺, 黄群邦, 刘擎旗, 等. 基于空域结构自适应拓扑的固定翼VTOL飞行器低空航迹规划方法[J]. 交通信息与安全, 2025, 43(3): 141-153. doi: 10.3963/j.jssn.1674-4861.2025.03.013YANG J T, HUANG Q B, LIU Q Q, et al. Low-altitude trajectory planning method for fixed-wing VTOL aircraft based on adaptive airspace structure topology[J]. Journal of Transport Information and Safety, 2025, 43(3): 141-153. (in Chinese) doi: 10.3963/j.jssn.1674-4861.2025.03.013 -

 点击查看大图
计量
- 文章访问数: 25
- HTML全文浏览量: 9
- PDF下载量: 0
- 被引次数: 0